CubeMars DW10 Underwater Thruster
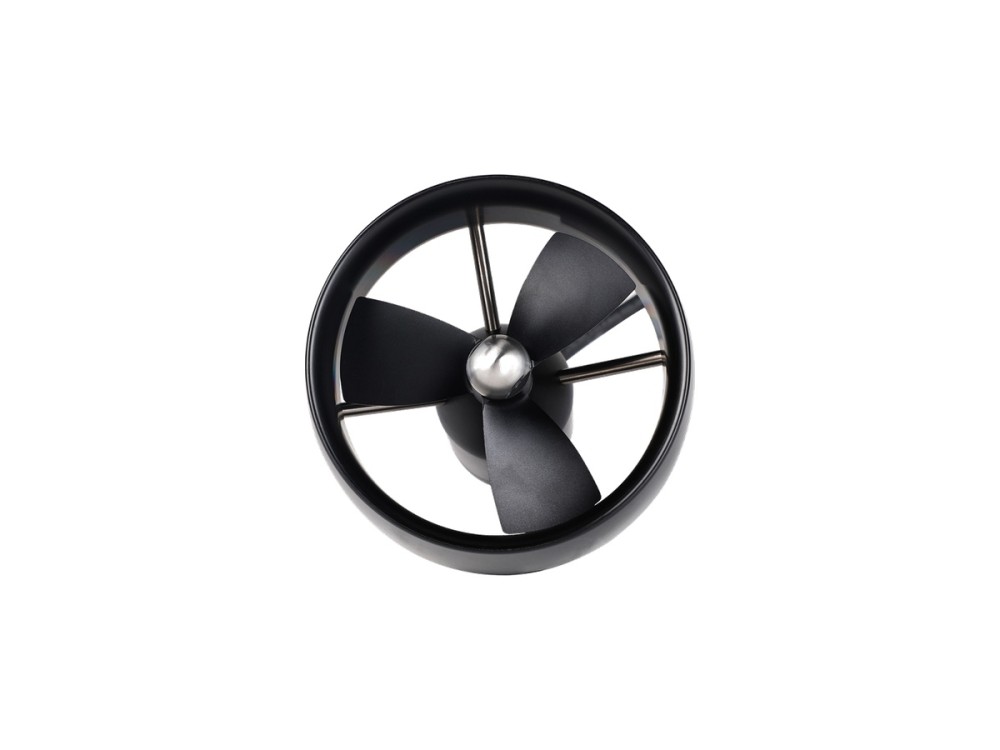
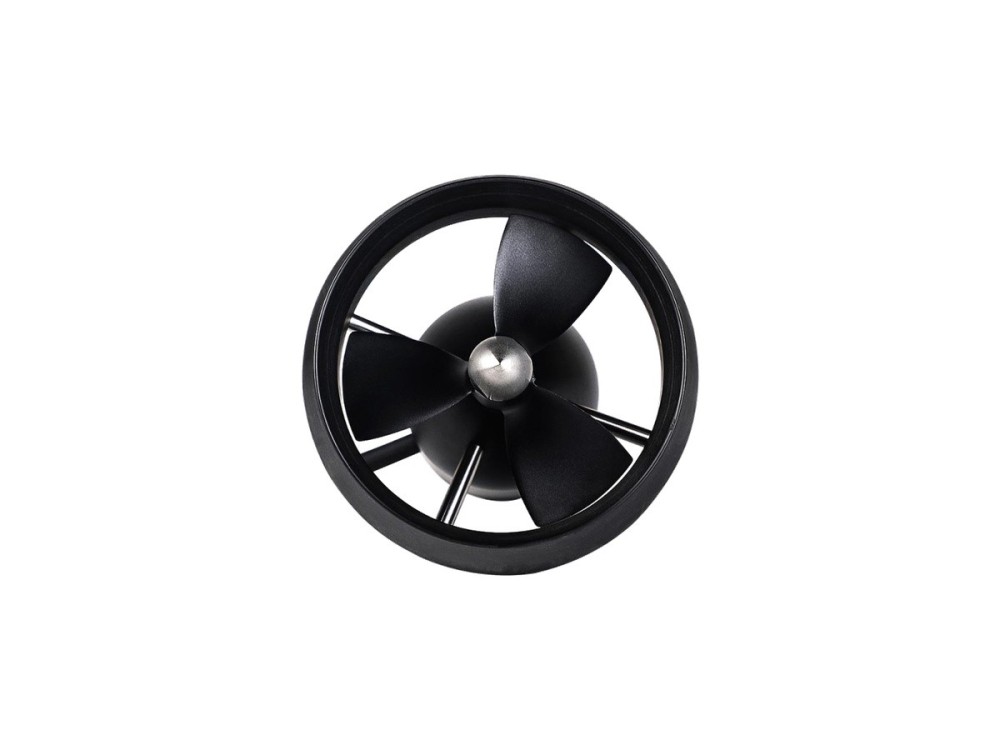
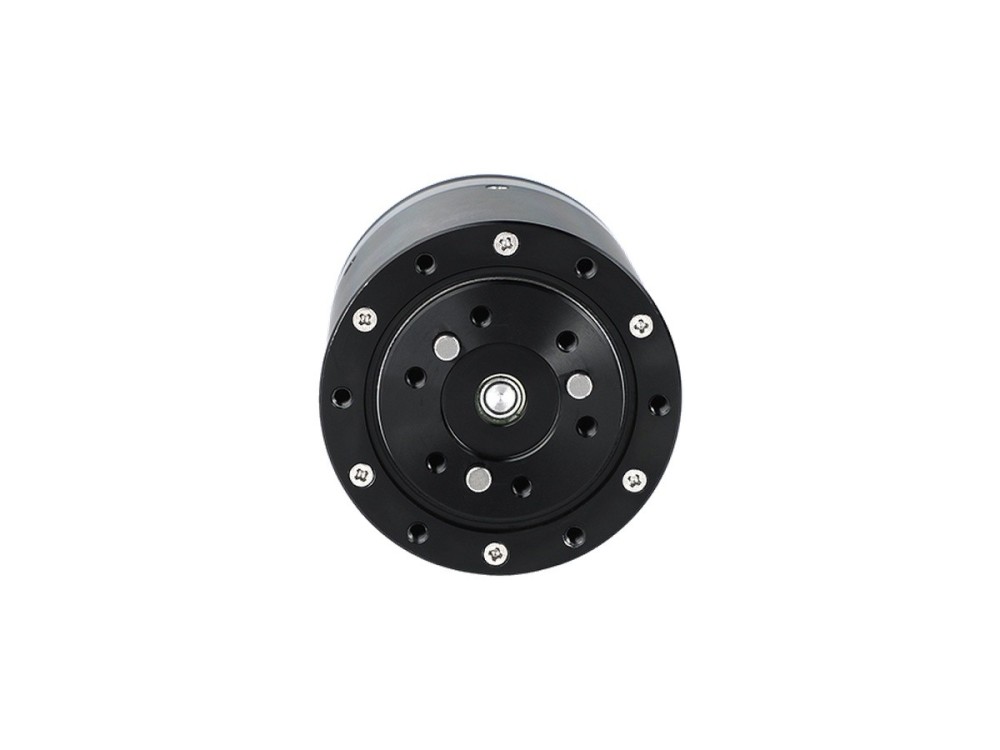
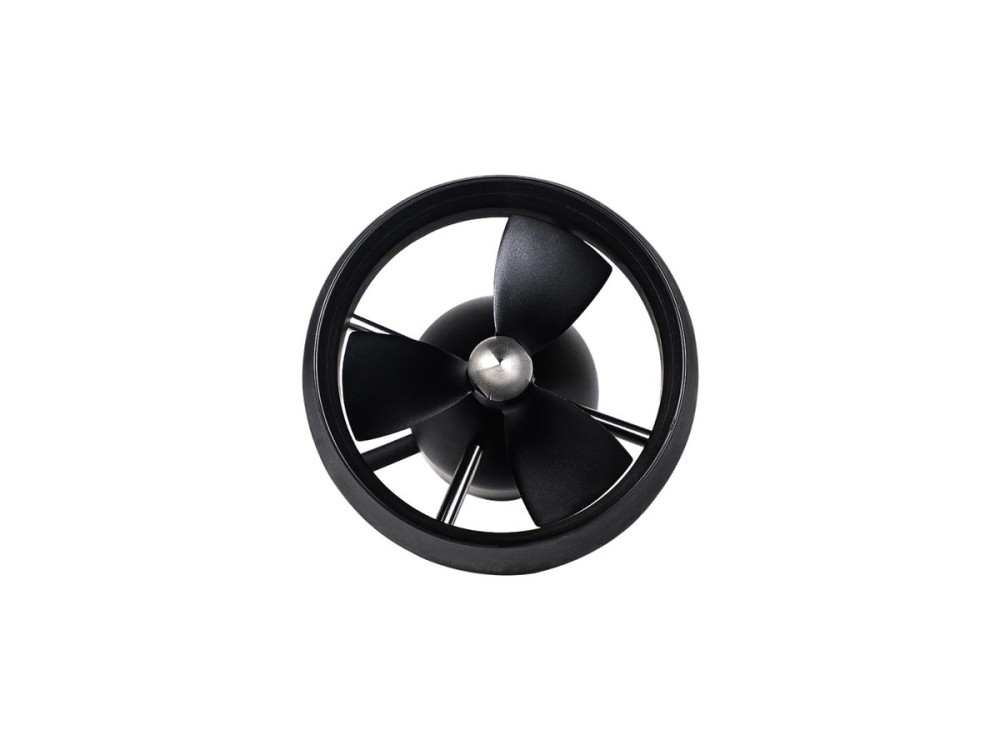
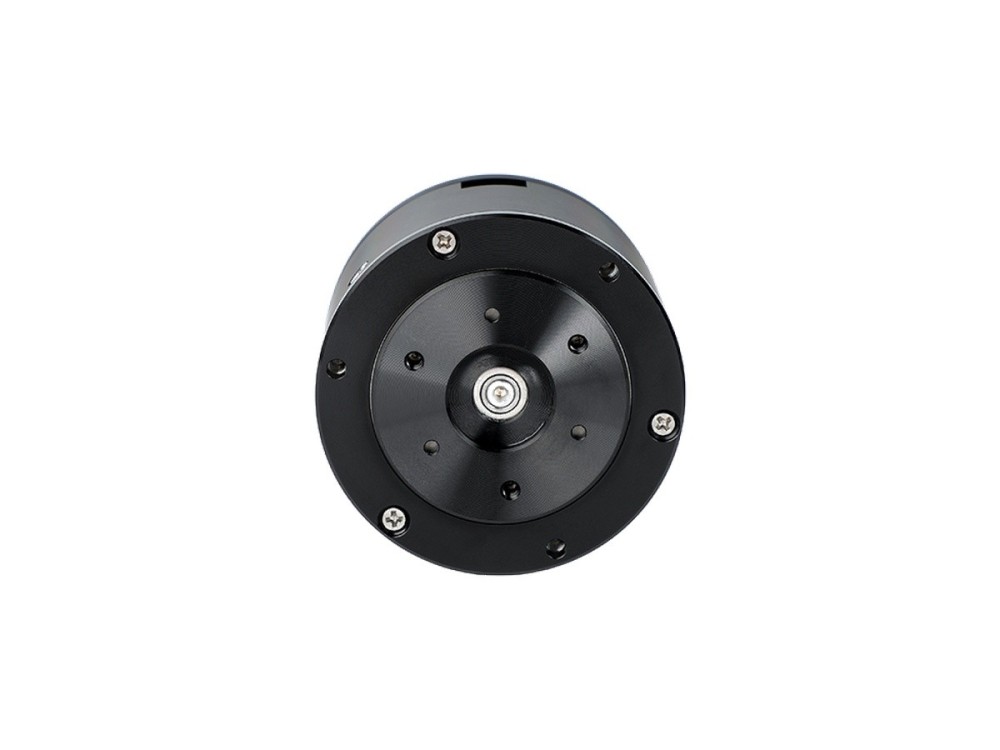
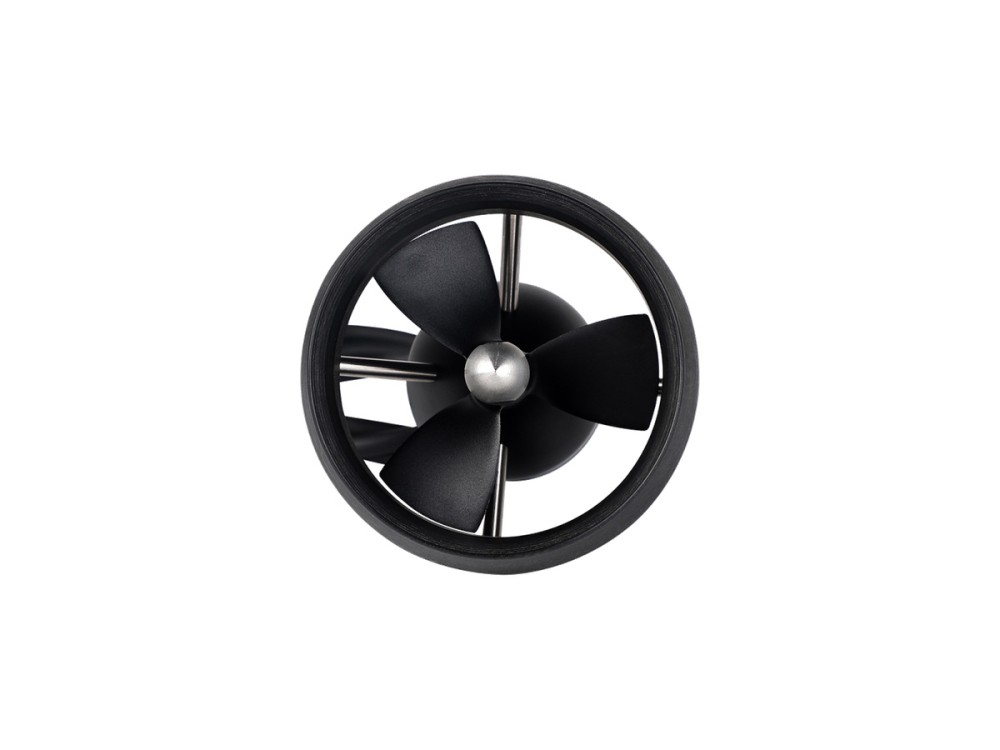
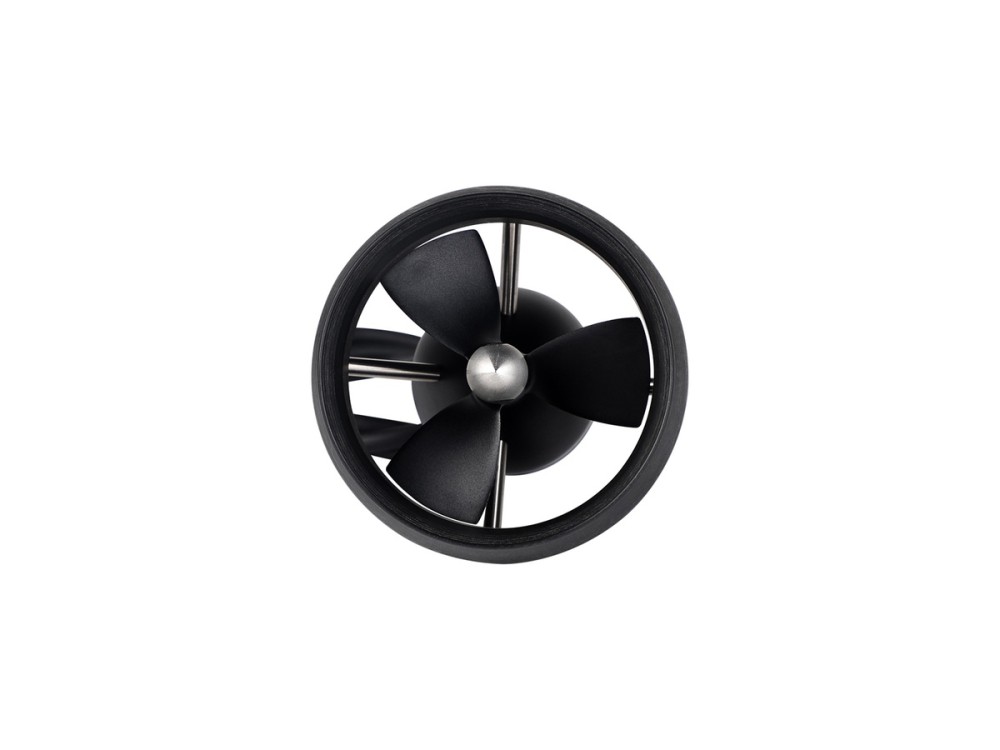
The DW10 underwater thruster provides 10 kgf of thrust with 540 W rated power at 36 V in a 100 mm, 840 g housing. Efficient and low noise, it suits ROV maneuvering and small underwater vehicles.
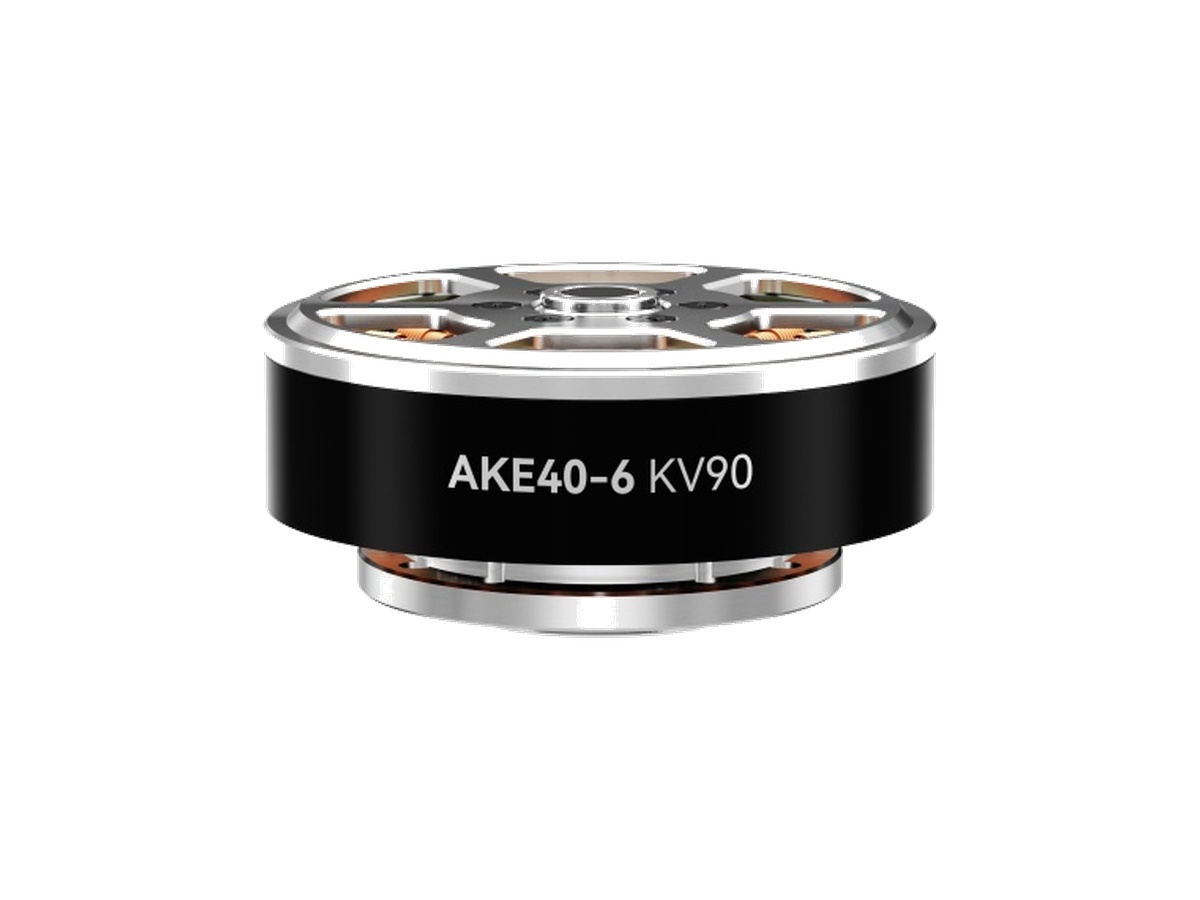
The CubeMars AKE40-6 KV90 quasi direct drive actuator integrates a brushless DC motor with a 6:1 planetary gearbox in a Ø51 x 24.5 mm, 140 g housing. On 24 V it delivers 50 W of continuous power, draws 2.5 A rated and 8 A peak current, reaches 260 rpm rated and 330 rpm no-load speed, and holds backlash to 9 arcmin with 0.05 N·m backdrive torque, suiting exoskeletons and lightweight robotic joints.
* Specifications are provided for reference. Please verify the latest specifications with the manufacturer.
The DW10 underwater thruster provides 10 kgf of thrust with 540 W rated power at 36 V in a 100 mm, 840 g housing. Efficient and low noise, it suits ROV maneuvering and small underwater vehicles.
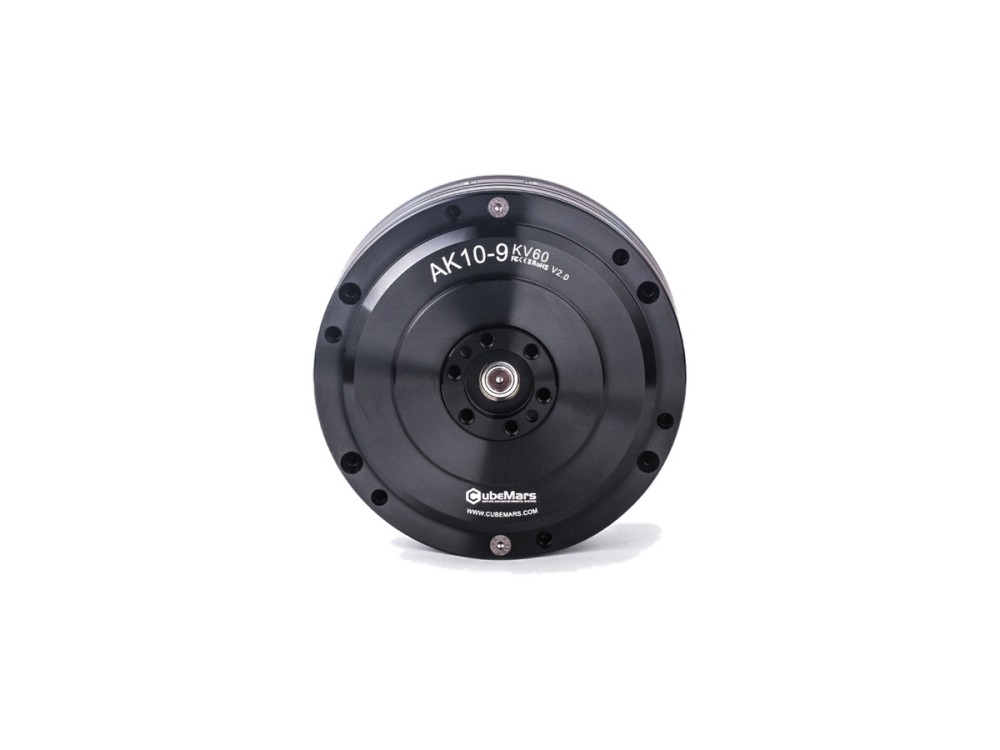
CubeMars AK10-9 V2.0 robotic actuator provides 48 Nm peak and 18 Nm rated torque via a 9:1 reducer, with dual encoders and 24/48 V flexibility. Weighing 960 g, it serves humanoid robots, exoskeletons and precision joint modules.
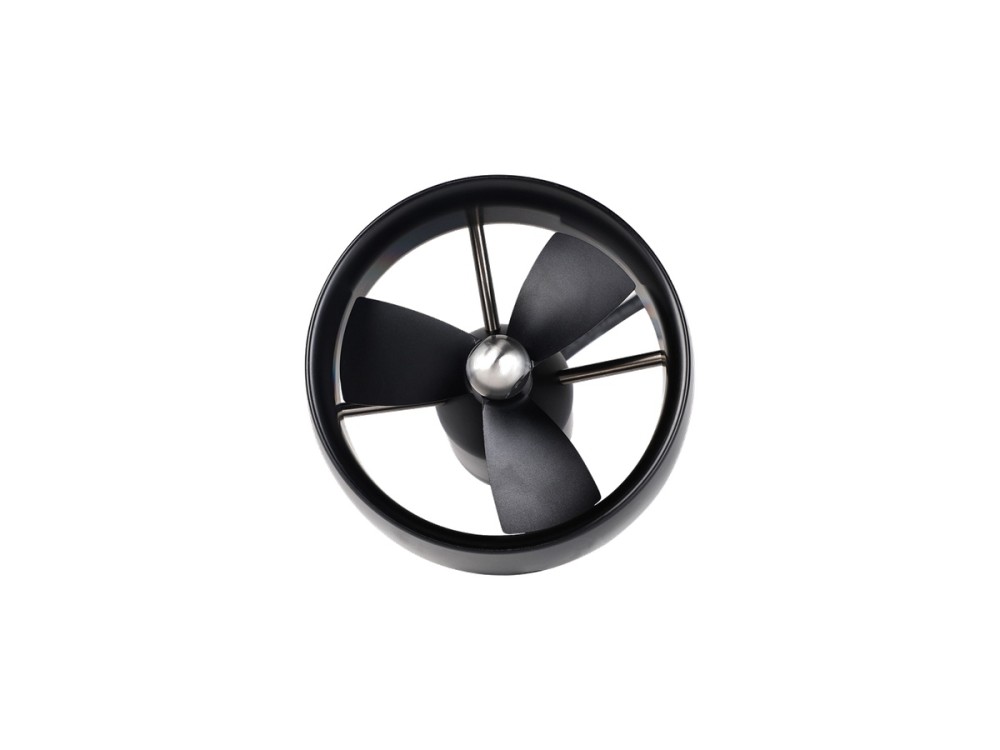
The DW20 underwater thruster outputs 20 kgf of thrust from 910 W rated power at 48 V. Its 152 mm, 1.63 kg sealed construction targets heavy ROV platforms and underwater manipulation tasks.
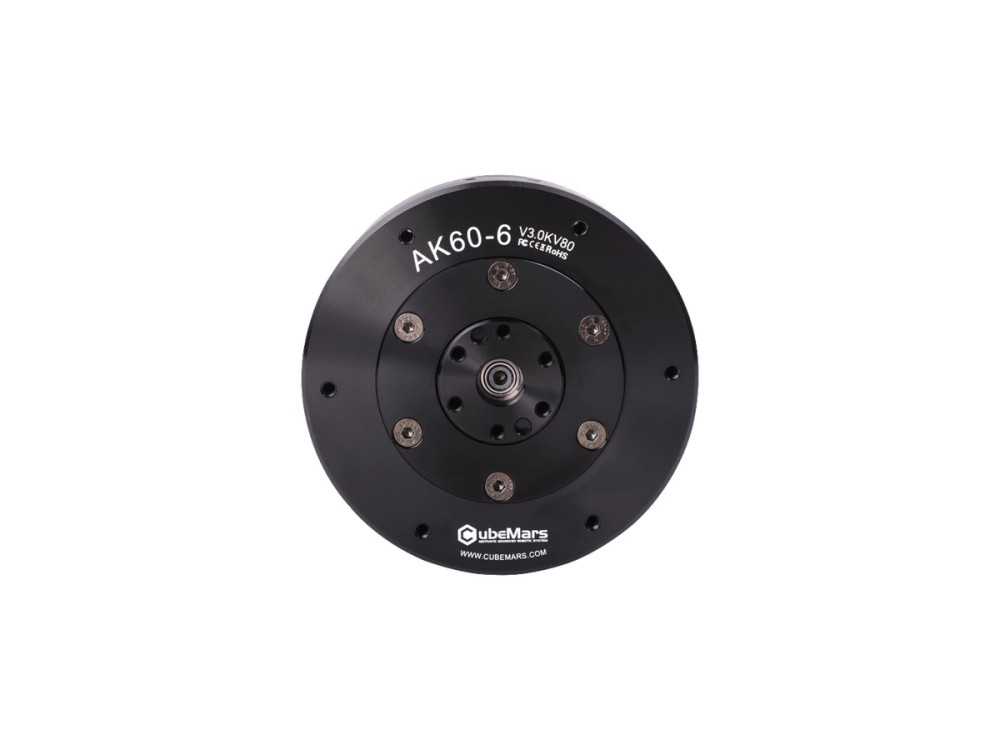
CubeMars AK60-6 V3.0 actuator delivers 9 Nm peak and 3 Nm rated torque through a compact 6:1 stage with 74 W rated power on 24/48 V. At 380 g and 79 mm, it serves light robotic arms, small joint modules and compact quadrupeds.
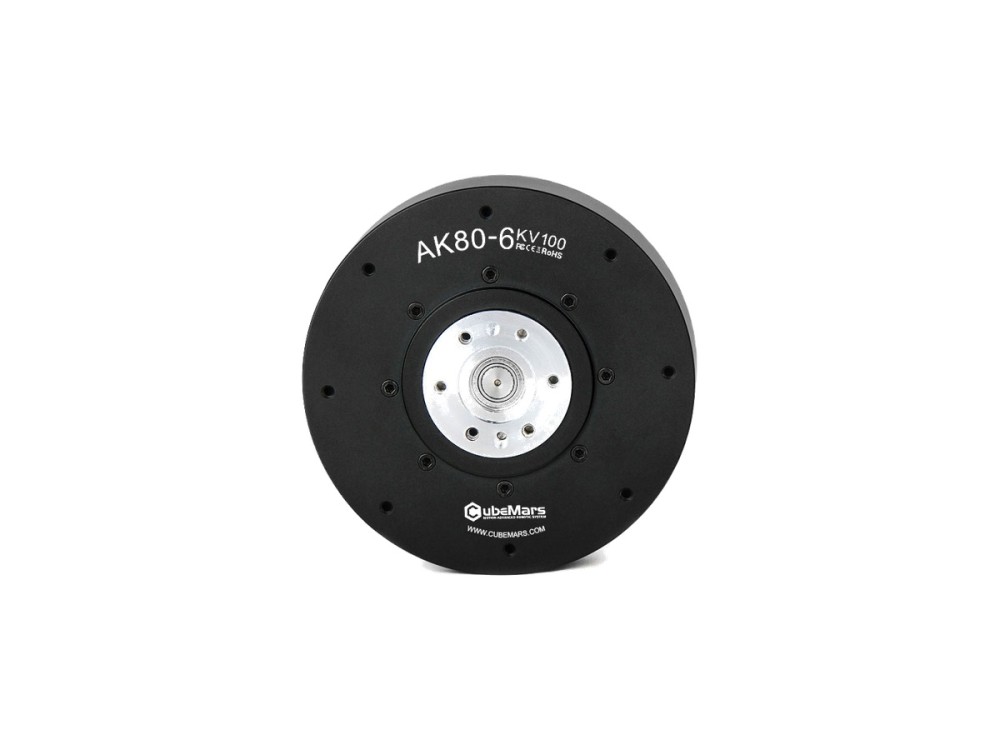
The AK80-6 V1.0 uses a 6:1 reduction for 12 Nm peak and 6 Nm rated torque, reaching 800 rpm no-load with 340 W rated power. Weighing 485 g at 48 V, it favors faster joints in humanoid arms and light quadruped robots.
CubeMars RI30 KV260 frameless torque motor packs 0.23 Nm peak and 0.076 Nm rated torque into a 38 mm, 40 g package. Rated 33 W at 24 V, it suits compact joint modules, collaborative robot arms and rehabilitation devices that need smooth, precise torque.
The AK60-6 V1.1 KV140 offers 9 Nm peak and 3 Nm rated torque with 130 W rated power at 24 V, reaching 560 rpm no-load. Its 368 g integrated body with 6:1 reducer fits nimble joints in desktop arms and small legged robots.
The RO100 KV55 Standard tops the RO range with 12 Nm peak and 4 Nm rated torque plus 838 W rated power at 48 V. Its 113 mm, 710 g frameless construction is built for demanding humanoid, quadruped and heavy-duty joint applications.
CubeMars AK45-10 V3.0 actuator delivers 7 Nm peak and 2.5 Nm rated torque through a 10:1 reducer, weighing 262 g at 53 mm diameter. Rated 39 W on a 24 V bus, it suits compact robot joints and rehabilitation exoskeletons.
CubeMars RO50 KV108 Lite frameless motor produces 0.9 Nm peak and 0.3 Nm rated torque while weighing just 105 g. With 66 W rated power at 24 V, it fits compact robotic joints where fast response and low weight matter.
CubeMars RI60 KV120 frameless inrunner delivers 1.63 Nm peak and 0.57 Nm rated torque at 85 W rated power. The 60 mm rotor runs on 24-48 V and weighs only 156 g, making it a strong fit for humanoid joints, wheel drives and collaborative arms.
The SW17 underwater thruster generates at least 17 kgf of thrust from 870 W rated power at 48 V. Its 1.35 kg sealed unit provides strong, clean power for work-class ROVs and underwater robots.
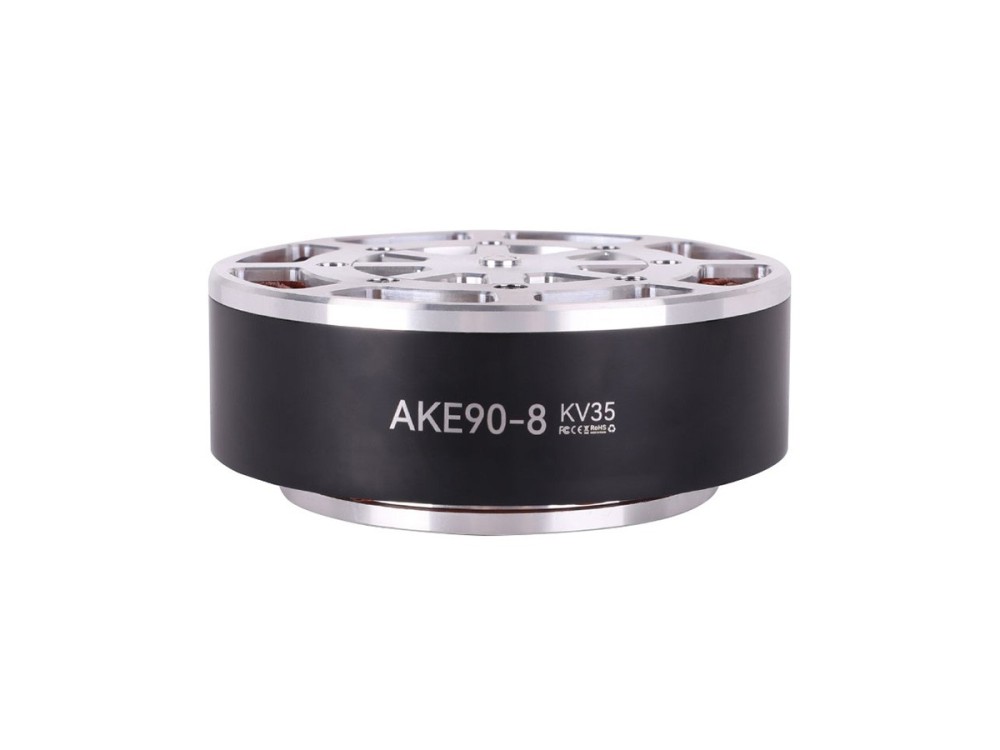
The AKE90-8 KV35 quasi-direct drive actuator combines an 8:1 planetary stage with low-inertia control, producing 170 Nm peak and 55 Nm rated torque. Weighing 1.4 kg at 48 V, it is aimed at humanoid legs, exoskeletons and high-dynamic joint modules.
The AK45-36 V3.0 pairs a KV80 motor with a 36:1 planetary reducer for 24 Nm peak and 8 Nm rated torque in a 349 g package. Running at 24 V, it is engineered for joint modules needing high reduction and precise, stable output.
The RI50 KV100 is a frameless inrunner torque motor built for 24-48 V systems. In a 54 mm, 181 g package it produces 1.67 Nm peak and 0.58 Nm rated torque with 66 W rated power, serving quadruped robots, exoskeletons, AGVs and robotic arm joints.
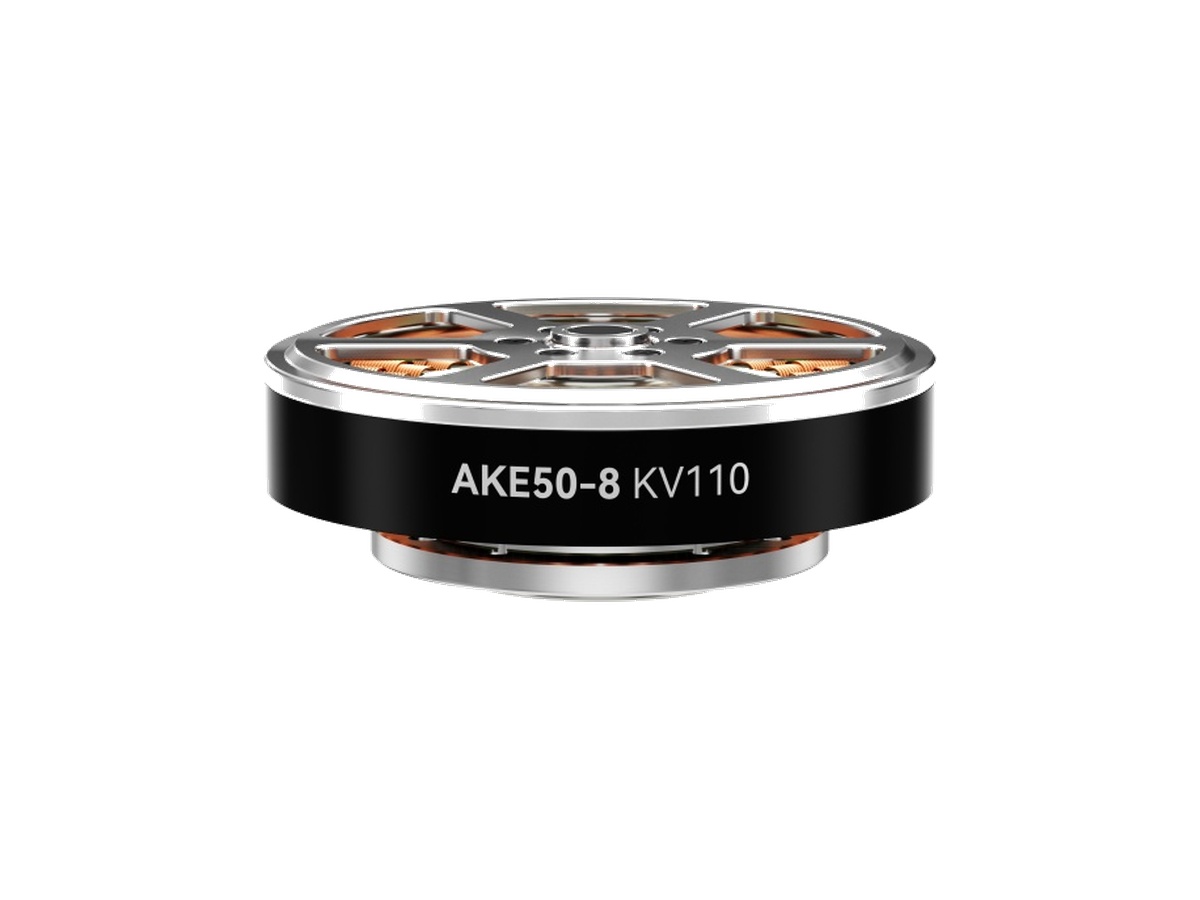
The CubeMars AKE50-8 KV110 quasi direct drive actuator integrates a brushless DC motor with an 8:1 planetary gearbox in a Ø61.2 x 22.5 mm, 190 g housing. On 24 V it delivers 65 W of continuous power, draws 3 A rated and 9 A peak current, reaches 240 rpm rated and 320 rpm no-load speed, and holds backlash to 9 arcmin with 0.09 N·m backdrive torque, suiting wearable devices, robotic joints and colla···
CubeMars SW12 underwater thruster delivers 12 kgf or more of thrust with 520 W rated power at 48 V. Weighing 1.18 kg, it offers efficient, corrosion-resistant propulsion for inspection-class ROVs.
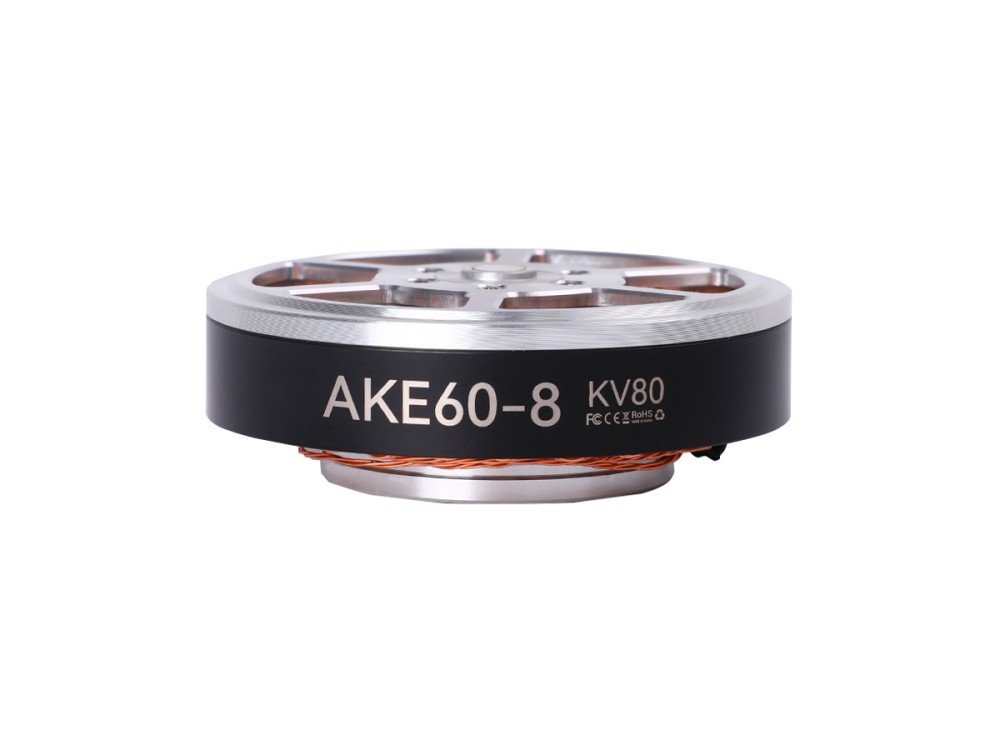
The AKE60-8 KV80 offers 12.5 Nm peak and 5 Nm rated torque via an 8:1 planetary stage at 24 V, weighing just 260 g. Its quasi-direct drive design gives low inertia and compliance for compact humanoid and exoskeleton joints.
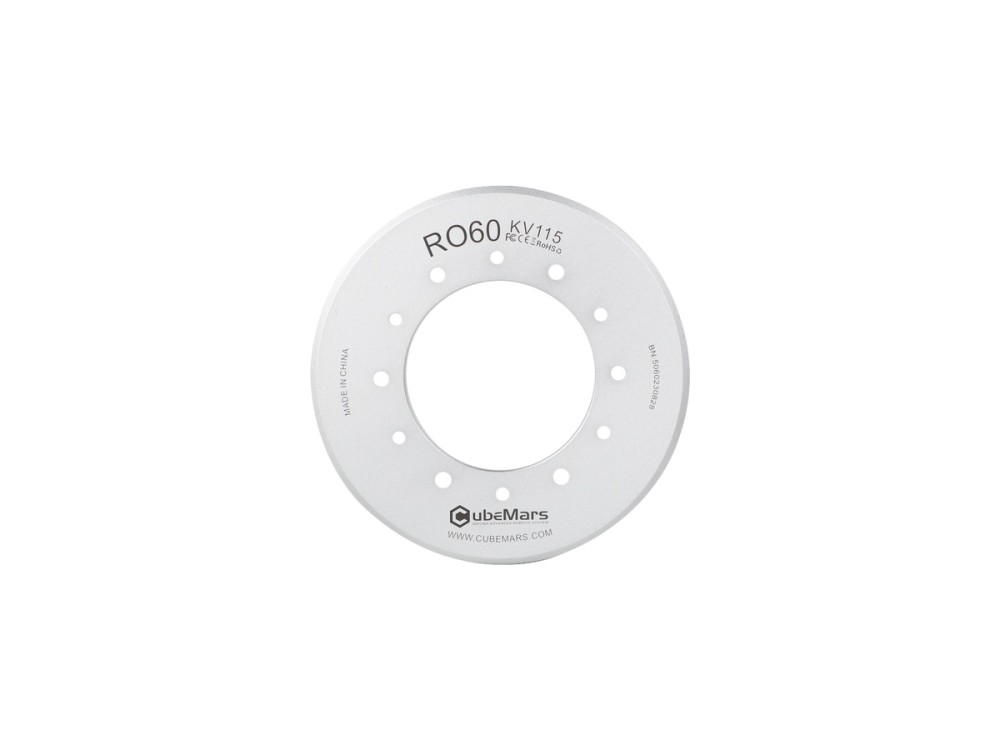
The RO60 KV115 Standard delivers 2.4 Nm peak and 0.8 Nm rated torque with 352 W rated power at 48 V, spinning to 5520 rpm no-load. The redesigned 74 mm, 248 g frameless platform offers high adaptability for humanoid and quadruped robot joints.
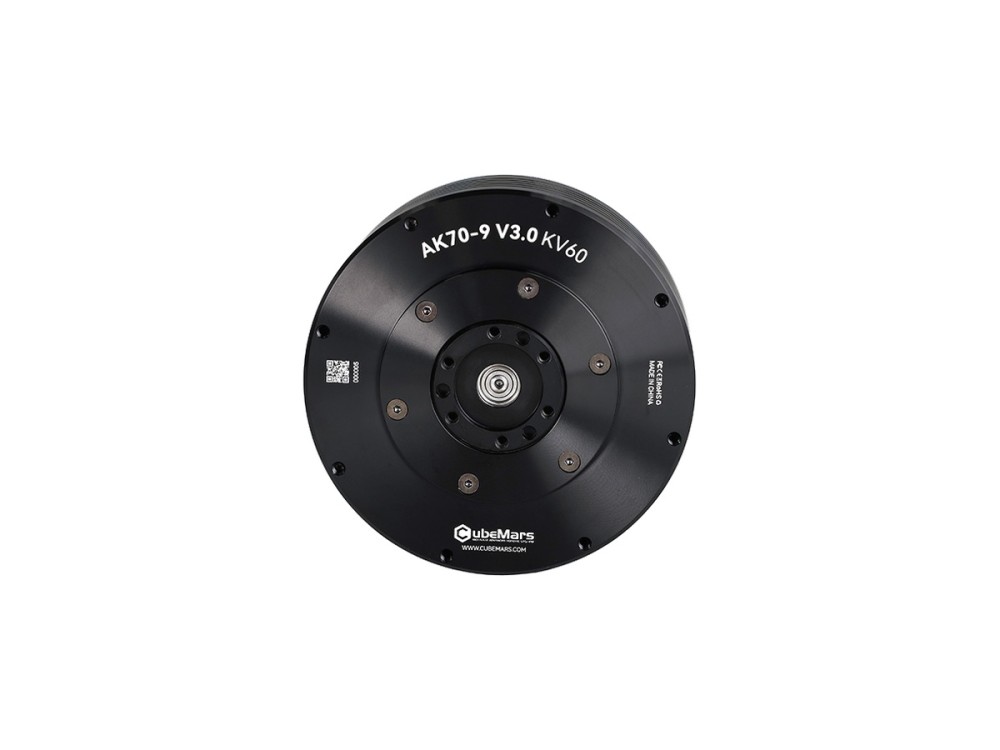
CubeMars AK70-9 V3.0 provides 29.2 Nm peak and 8.5 Nm rated torque through a 9:1 reducer with 231 W rated power at 48 V. Its 89 mm, 540 g housing integrates dual encoders for humanoid legs, exoskeletons and arm joints.
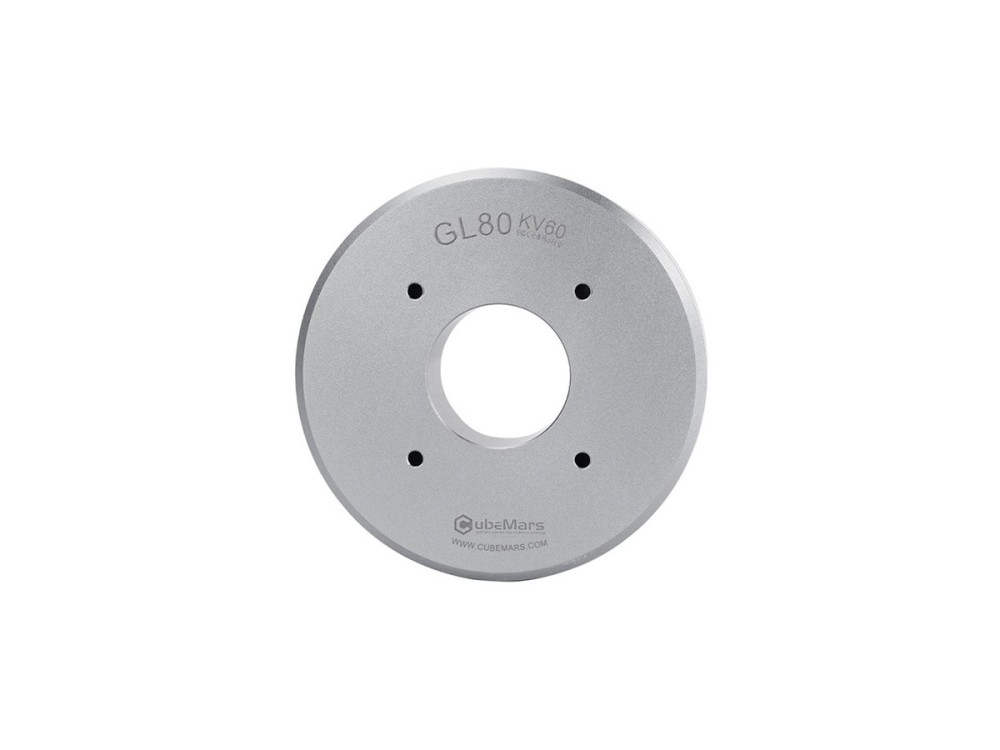
The GL80 KV30 gimbal motor handles 2.9 Nm peak and 1 Nm rated torque with 48 W rated power at 24 V. Weighing 312 g with an 87 mm stator, it drives medium and large gimbal axes with smooth precision.
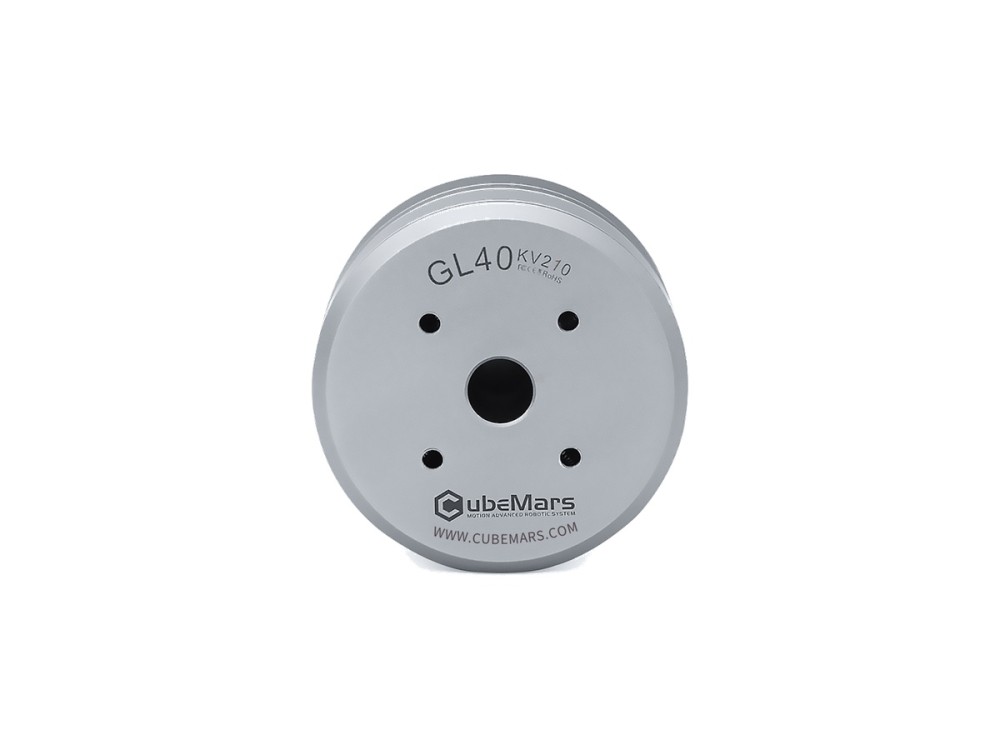
The GL40 KV70 gimbal motor delivers 0.5 Nm peak and 0.25 Nm rated torque in a 107 g, 46.5 mm direct-drive body. Low cogging and smooth control suit handheld and drone-mounted camera stabilizers.
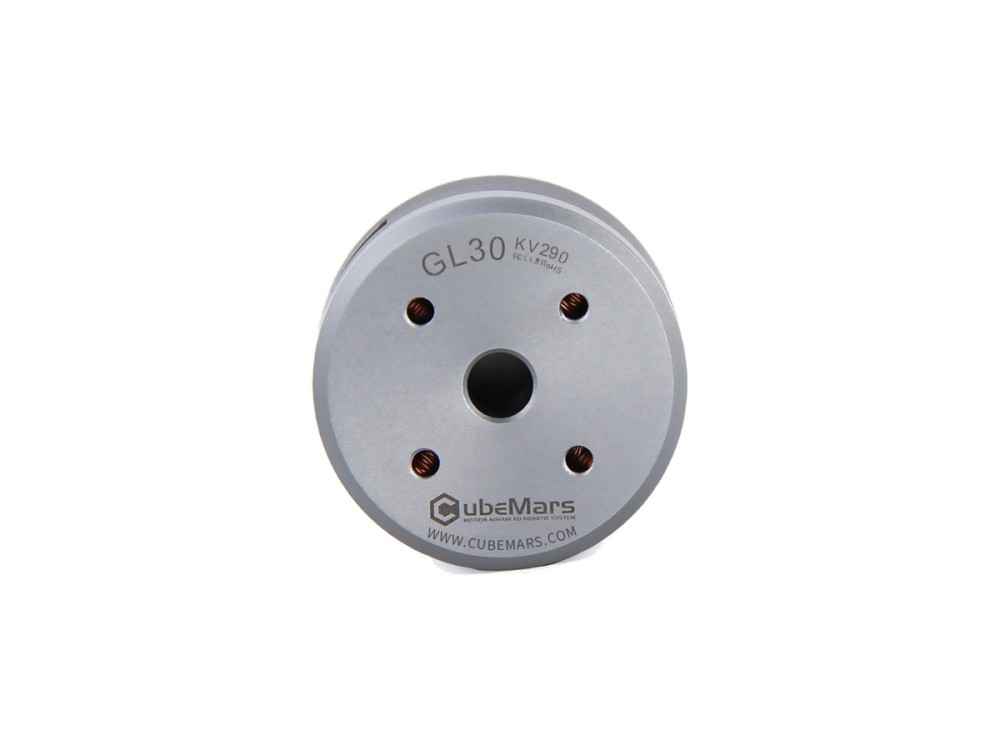
The GL30 KV290 is an ultralight 41 g gimbal motor with 0.28 Nm peak torque in a 34.5 mm frame. Designed for 12 V systems, it brings precise direct-drive stabilization to compact camera gimbals.
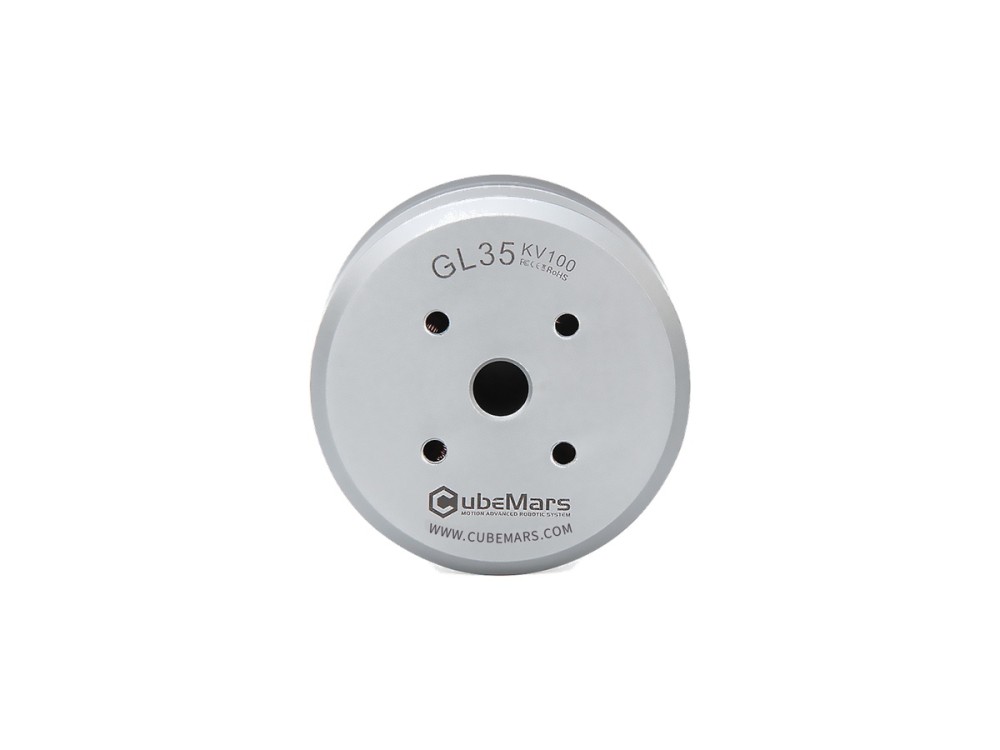
CubeMars GL35 gimbal motor outputs 0.46 Nm peak and 0.15 Nm rated torque while weighing only 90 g. The 41.8 mm direct-drive unit offers low cogging torque for smooth small gimbal and pointing applications.
The RO40 KV140 Lite is a 60 g frameless torque motor with 0.6 Nm peak and 0.2 Nm rated torque in a compact 46 mm format. Rated 51 W at 24 V, it brings responsive direct-drive motion to lightweight robotic joints.
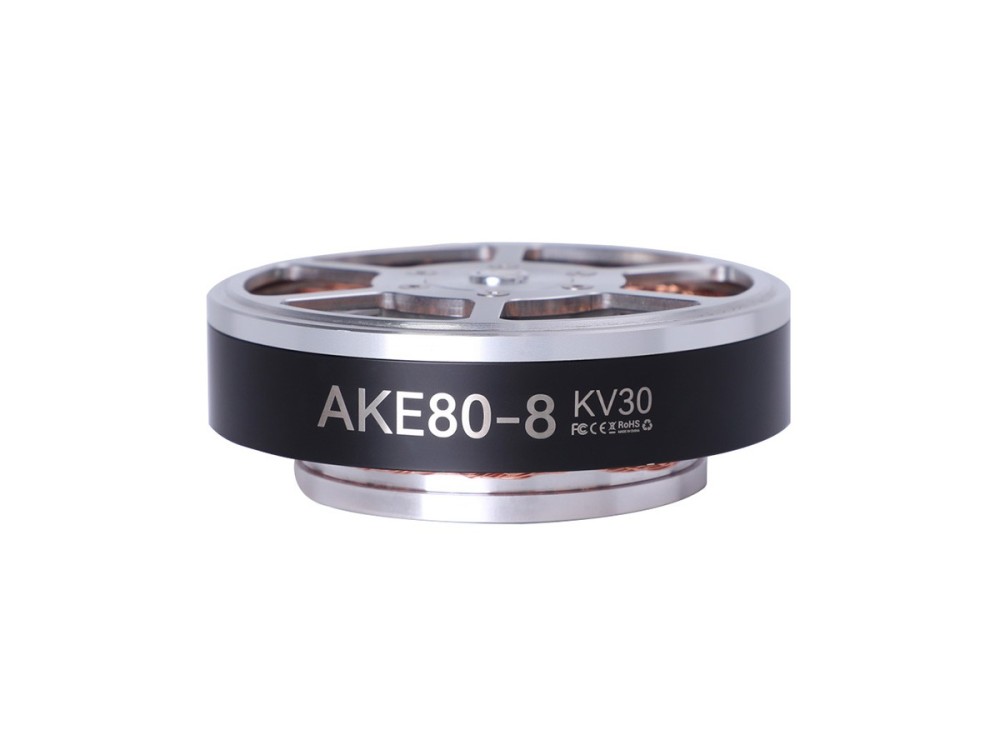
CubeMars AKE80-8 KV30 quasi-direct drive actuator delivers 30 Nm peak and 12 Nm rated torque through an 8:1 reducer on a 48 V supply. At 570 g, its low inertia and backdrivability suit exoskeletons, rehabilitation robots and legged joints.
The CubeMars AKE40-6 KV90 quasi direct drive actuator integrates a brushless DC motor with a 6:1 planetary gearbox in a Ø51 x 24.5 mm, 140 g housing. On 24 V it delivers 50 W of continuous power, draws 2.5 A rated and 8 A peak current, reaches 260 rpm rated and 330 rpm no-load speed, and holds backlash to 9 arcmin with 0.05 N·m backdrive torque, suiting exoskeletons and lightweight robotic joints.
The RI100 KV105 is the largest RI inrunner, delivering 4.95 Nm peak and 1.76 Nm rated torque with 252 W rated power. Its 104 mm, 500 g frameless design on a 24-48 V bus serves humanoid robots, exoskeletons and high-load joint modules.
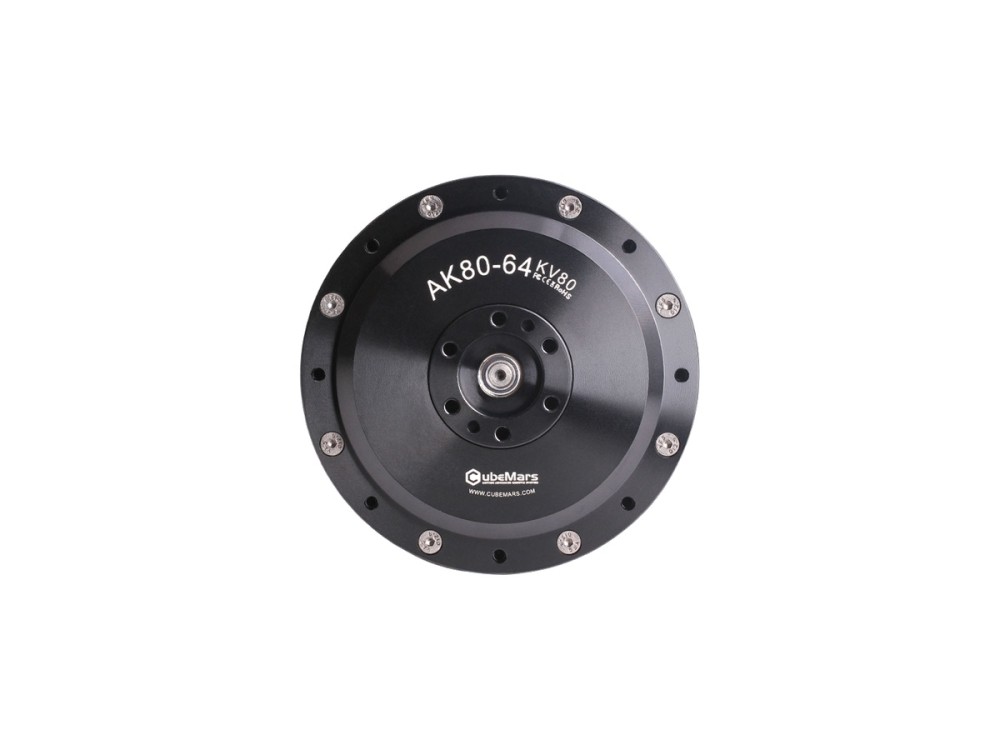
CubeMars AK80-64 actuator mounts a KV80 motor on a 64:1 planetary reducer, producing 120 Nm peak and 48 Nm rated torque in an 850 g body. Accepting 24/48 V, it targets high-load joints on legged robots and heavy manipulators.
The CubeMars RI20 KV600 is an ultra-compact frameless inner-rotor torque motor weighing just 20 g with a 25 mm diameter. It delivers 0.072 Nm peak and 0.024 Nm rated torque at up to 18 W, ideal for rehabilitation robots, joint modules and compact robotic arms.
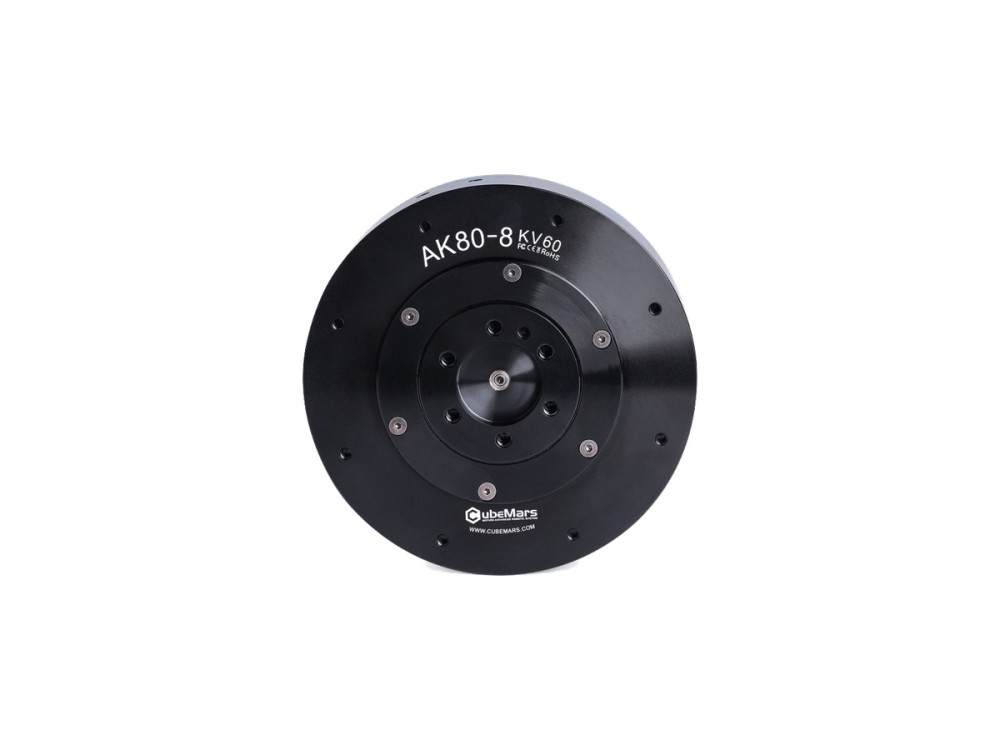
CubeMars AK80-8 actuator integrates an 8:1 reducer for 25 Nm peak and 10 Nm rated torque with 230 W rated power on a 48 V bus. The 570 g unit is widely used in exoskeletons, quadrupeds and collaborative robot joints.
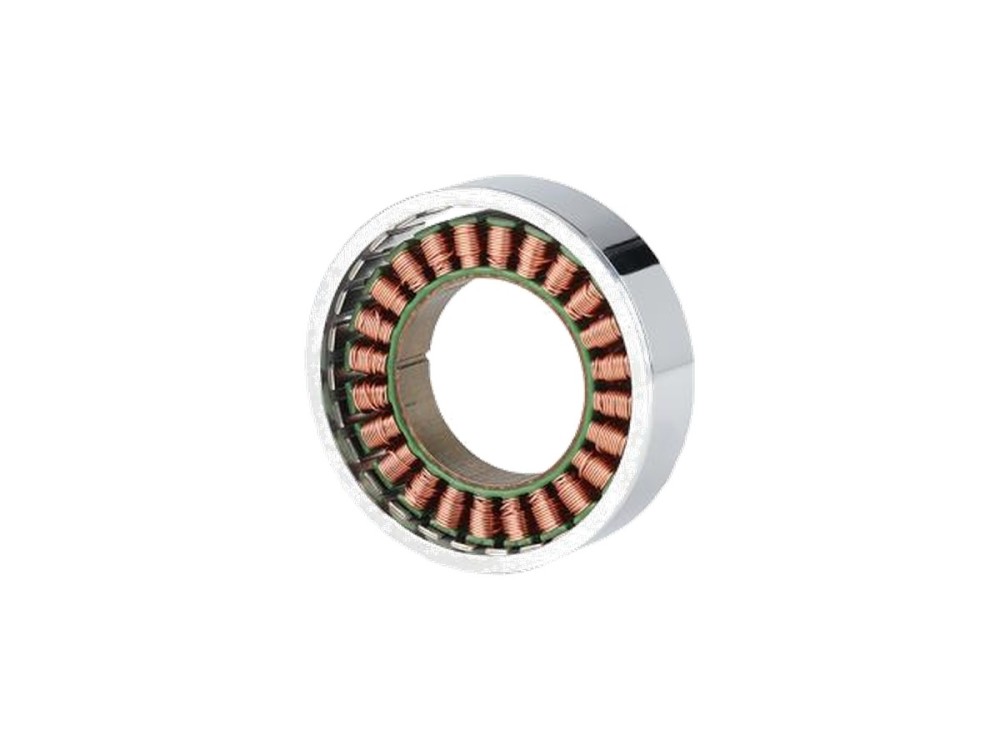
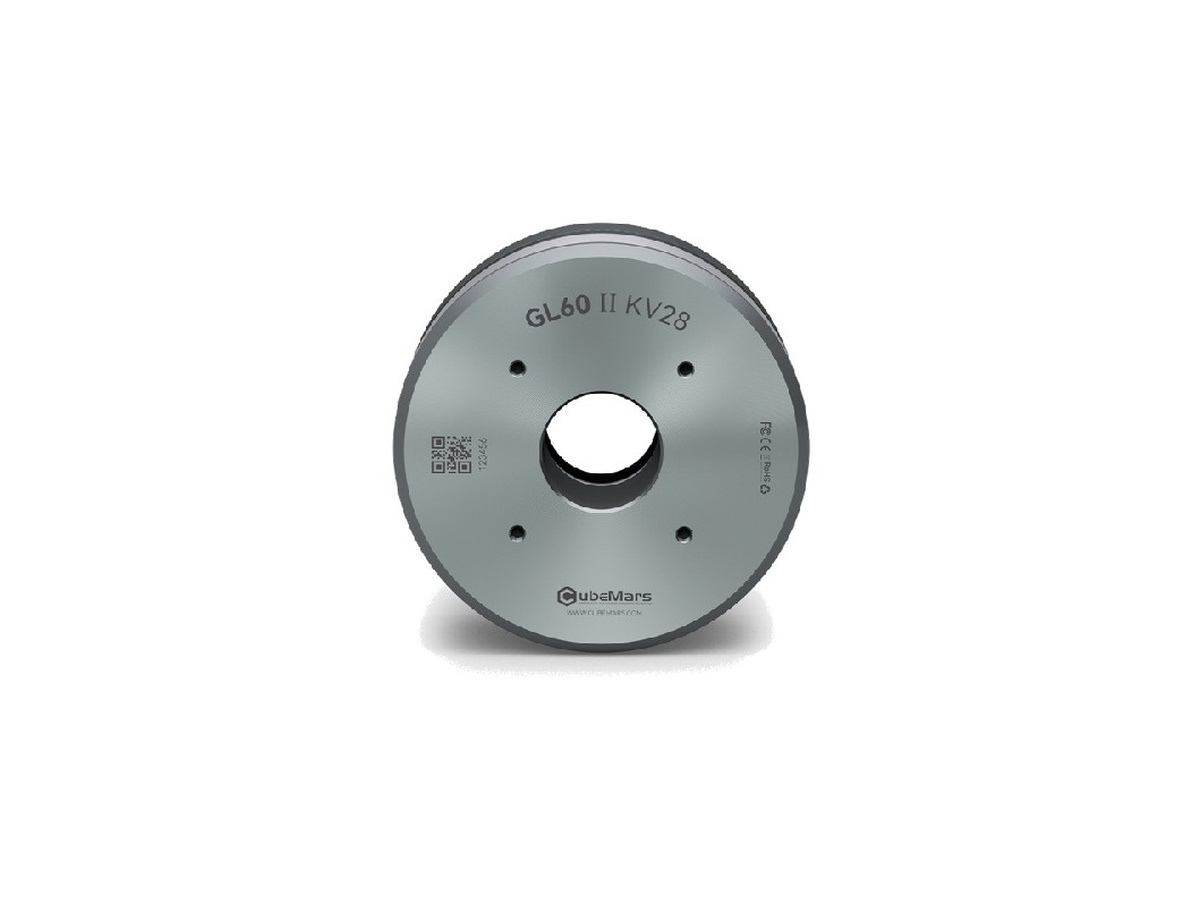
CubeMars GL60 II KV28 gimbal motor provides 1.5 Nm peak and 0.6 Nm rated torque at just 276 g. Its low cogging design and 24N28P stator deliver smooth, stable camera stabilization for high-end gimbal systems.
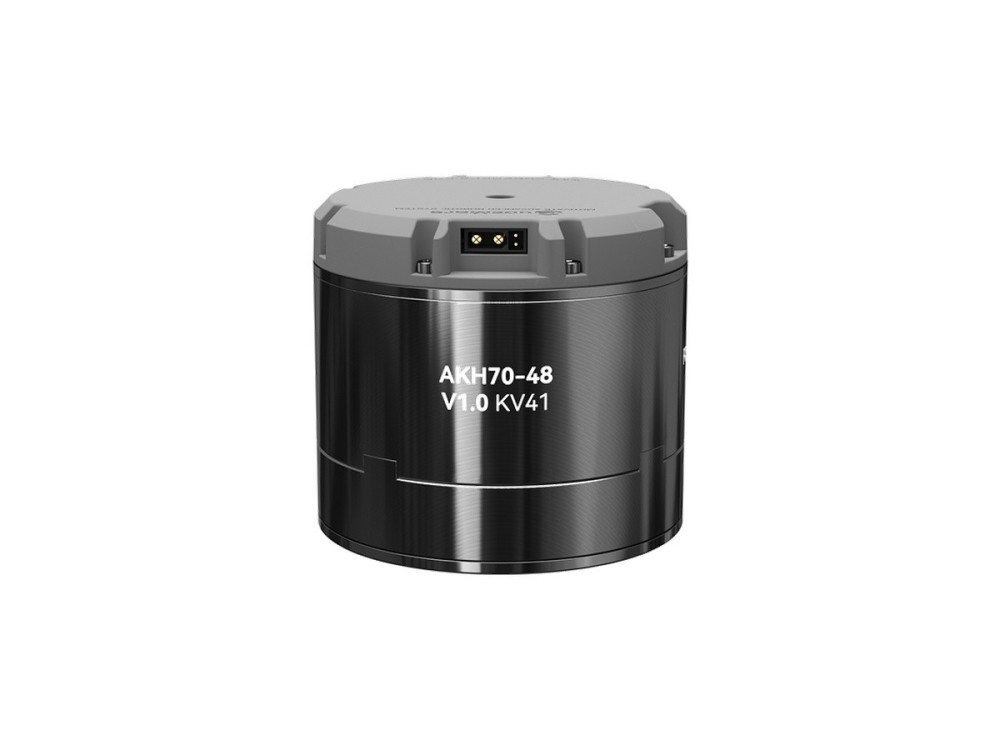
The AKH70-48 V1.0 hollow-shaft planetary actuator delivers 222 Nm peak and 74 Nm rated torque through a 48:1 reducer at 48 V. Weighing 1.4 kg with cable pass-through, it powers heavy legged robots, AGV drives and large joint modules.
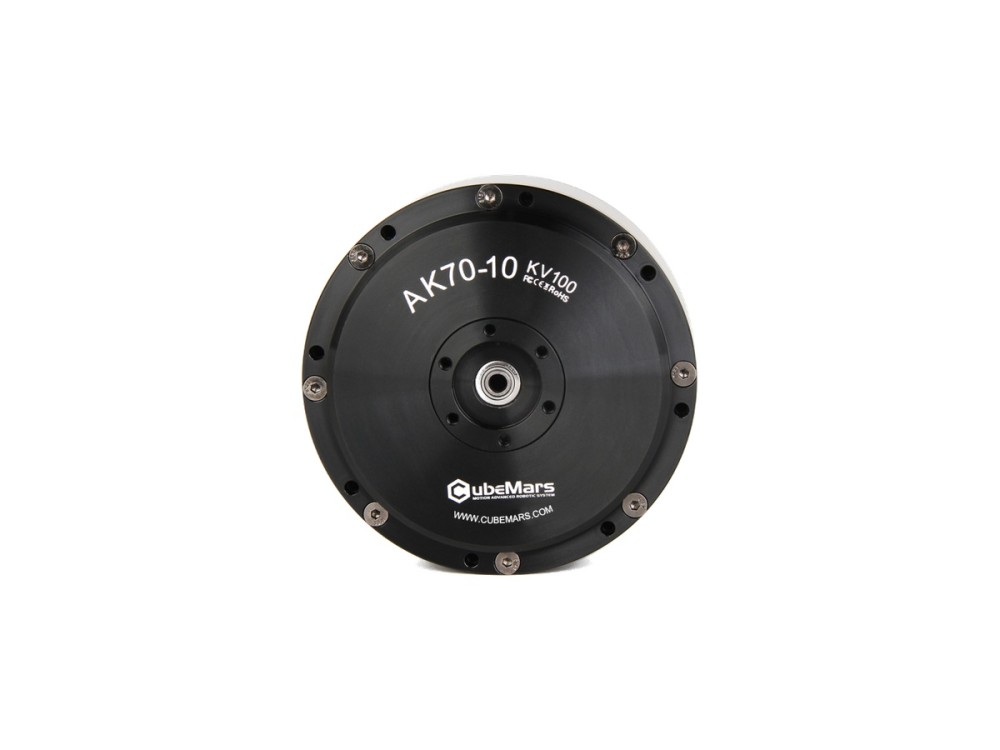
The AK70-10 pairs a 10:1 planetary stage with a single 14-bit magnetic encoder, delivering 24.8 Nm peak and 8.3 Nm rated torque plus 230 W rated power. The 621 g actuator runs on 24/48 V and suits exoskeleton joints, quadrupeds and robot arms.
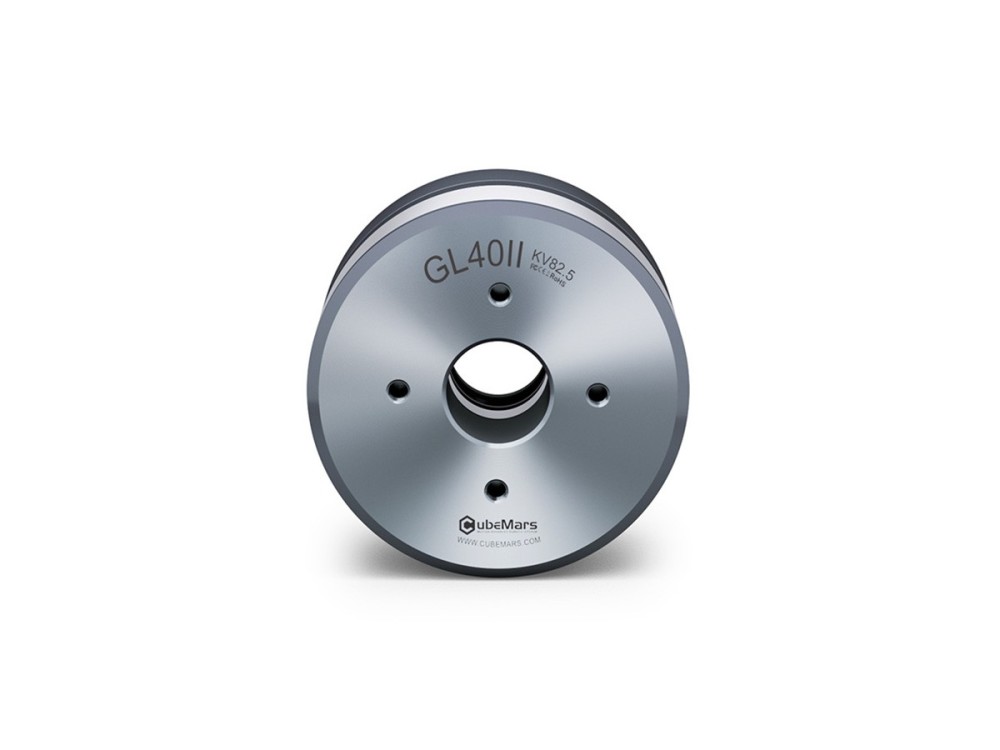
The GL40 II KV82.5 is a direct-drive gimbal motor with 0.68 Nm peak and 0.25 Nm rated torque in a 125 g body. Low cogging and smooth torque make it well suited to camera stabilizers and precision pointing applications.
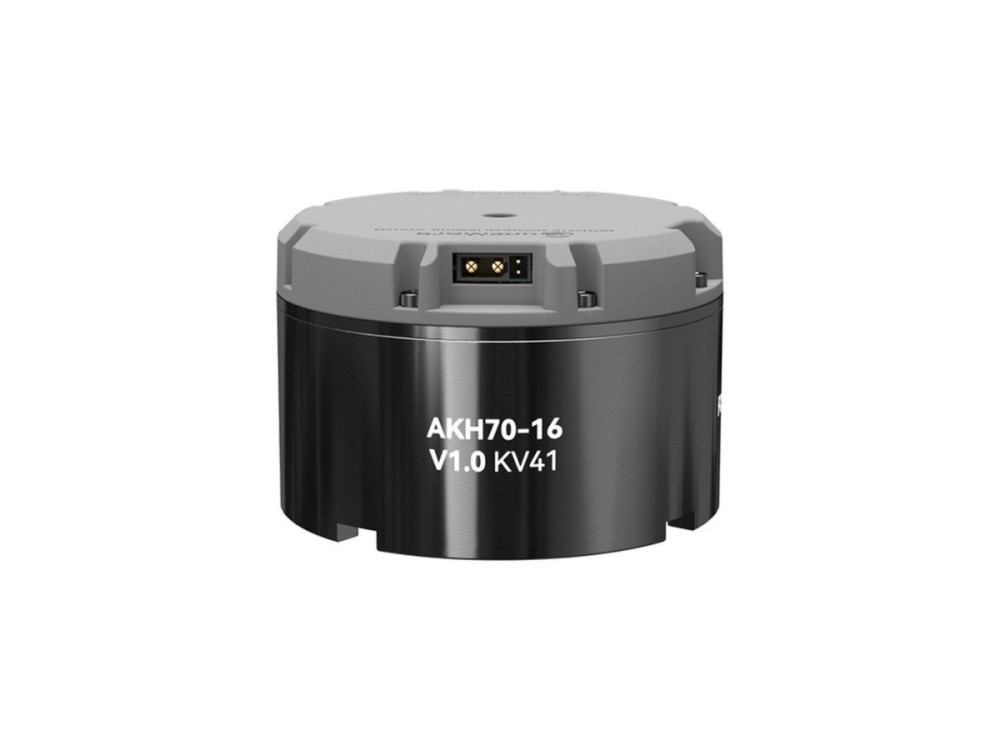
CubeMars AKH70-16 V1.0 combines a hollow shaft with a 16:1 planetary stage for 78 Nm peak and 26 Nm rated torque. The 879 g actuator runs on 48 V and fits quadruped knees, robotic arm joints and wheeled drives needing internal cable routing.
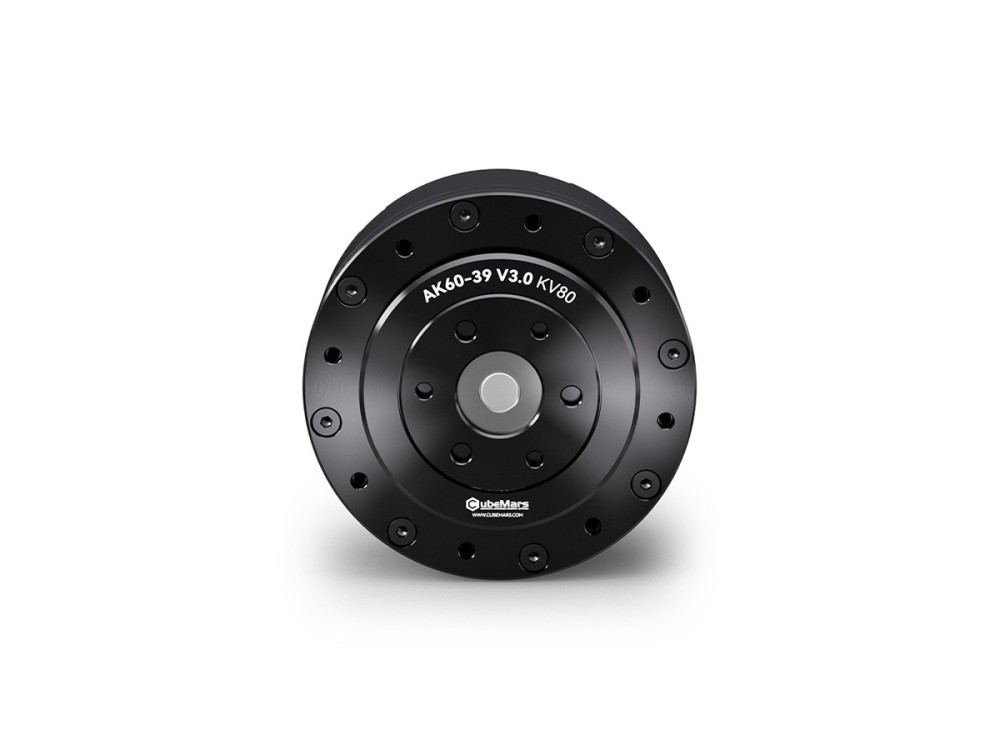
The AK60-39 V3.0 pairs a KV80 motor with a 39:1 reducer for 72 Nm peak and 24 Nm rated torque, with 176 W rated power at 48 V. Weighing 750 g, it is built for load-bearing joints in legged robots and industrial manipulators.
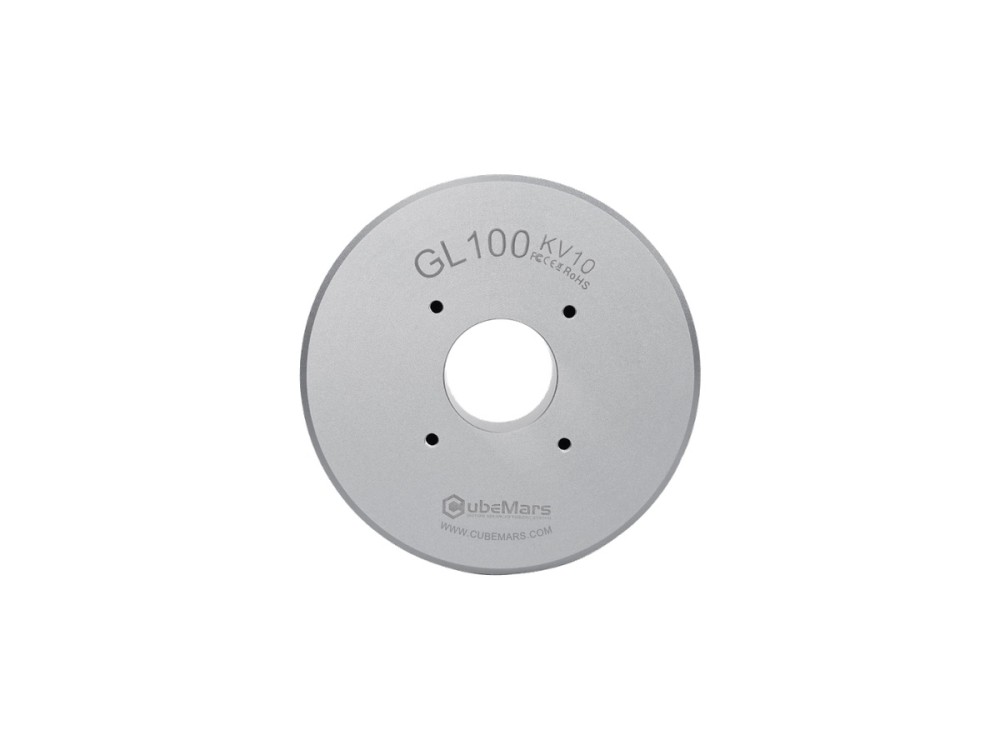
CubeMars GL100 KV10 is the largest GL gimbal motor, delivering 7.7 Nm peak and 3 Nm rated torque for heavy camera payloads. The 107 mm, 698 g direct-drive unit at 24 V stabilizes cinema-grade gimbals.
The CubeMars SW7 underwater thruster produces over 7 kgf of thrust with 360 W rated power at 36 V in a compact 700 g body. An optimized propeller and sealing design make it a reliable propulsion choice for small ROVs and AUVs.
The AK40-10 V3.0 is an ultralight 190 g robotic actuator integrating a BLDC motor, 10:1 planetary gearbox and driver. It provides 4.1 Nm peak and 1.3 Nm rated torque at 24 V, ideal for dexterous robotic arms and small joint modules.
CubeMars DW25 is the flagship DW thruster with 25 kgf of thrust and 1315 W rated power at 48 V. The 1.79 kg unit provides powerful, reliable propulsion for large ROVs and heavy underwater vehicles.
The RI70 KV95 offers 2.68 Nm peak and 0.94 Nm rated torque with 125 W rated power in a 76 mm frameless inrunner body of 270 g. Designed for 24-48 V buses, it targets legged robots, joint modules and precision robotic arms.
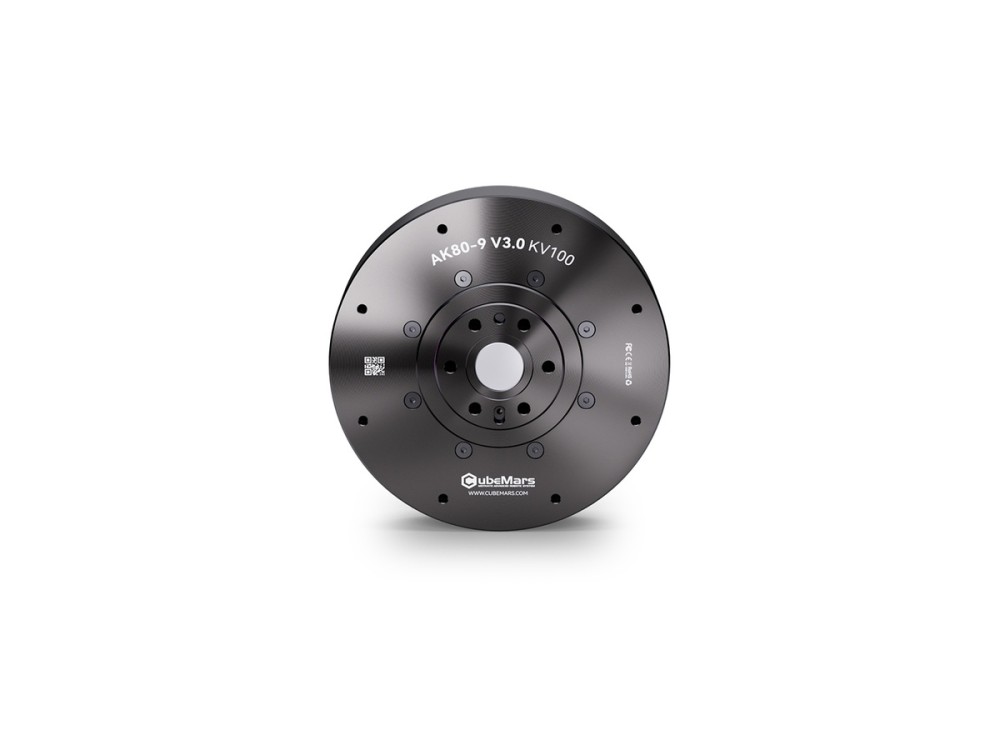
The AK80-9 V3.0 packs a BLDC motor, 9:1 planetary gearbox and driver into a 98 mm, 490 g actuator. It delivers 22 Nm peak and 9 Nm rated torque with 368 W rated power at 48 V for agile legged robots and compact arms.
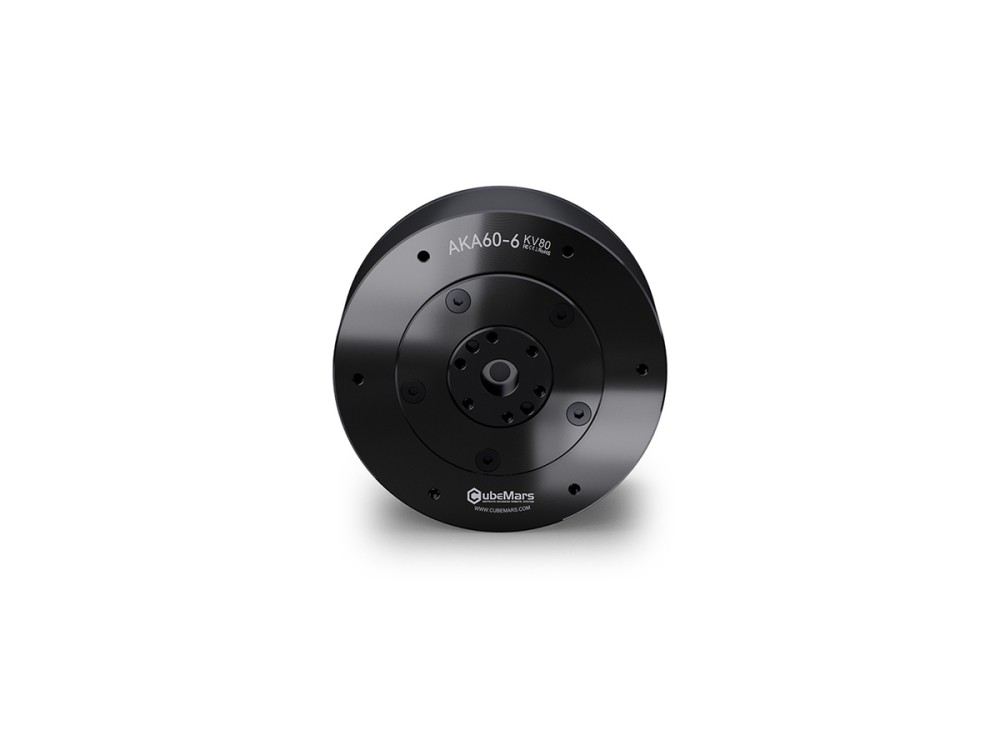
Designed for wheeled robots and AGVs, the AKA60-6 KV80 actuator provides 9 Nm peak and 3 Nm rated torque through a 6:1 reducer with reinforced radial load capacity. It weighs 460 g, runs on 24/48 V and outputs 62 W rated power.
CubeMars RI80 V2.0 KV75 steps up to 4.1 Nm peak and 1.45 Nm rated torque with 172 W rated power. The 85 mm, 411 g frameless inrunner accepts 24-48 V input and fits humanoid robots, exoskeletons, quadrupeds and heavy joint modules.
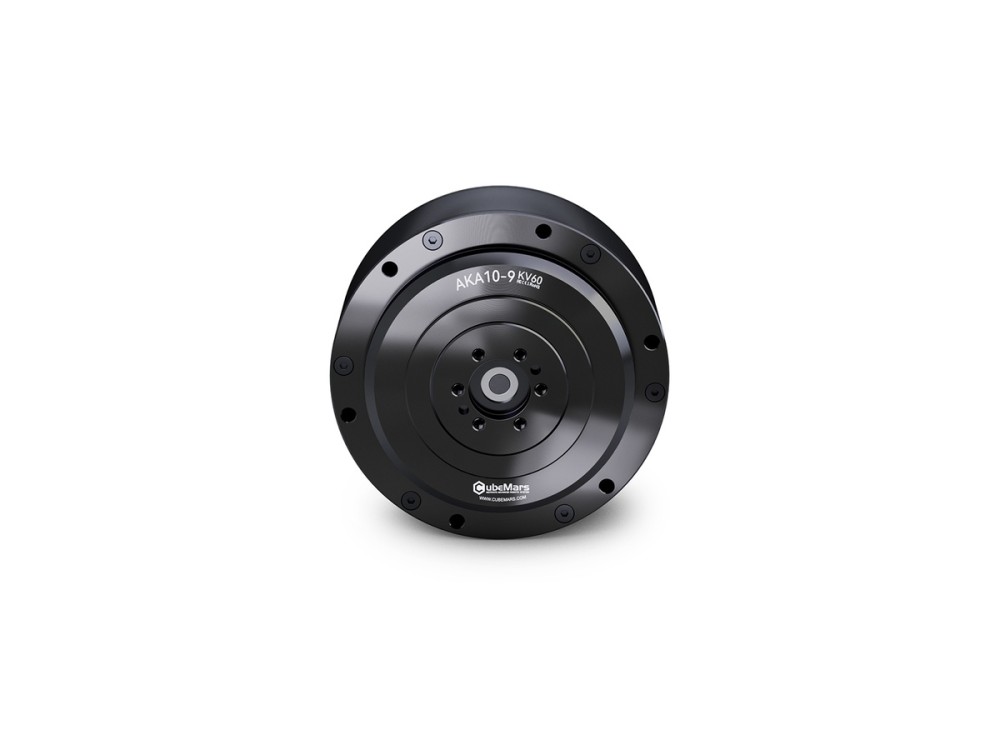
The AKA10-9 KV60 is a wheel-drive actuator for AGVs and wheeled robots, delivering 53 Nm peak and 18 Nm rated torque with 120 percent higher radial load capacity. Its 9:1 reducer, single 16-bit magnetic encoder and 48 V, 205 W rated power ensure robust traction.
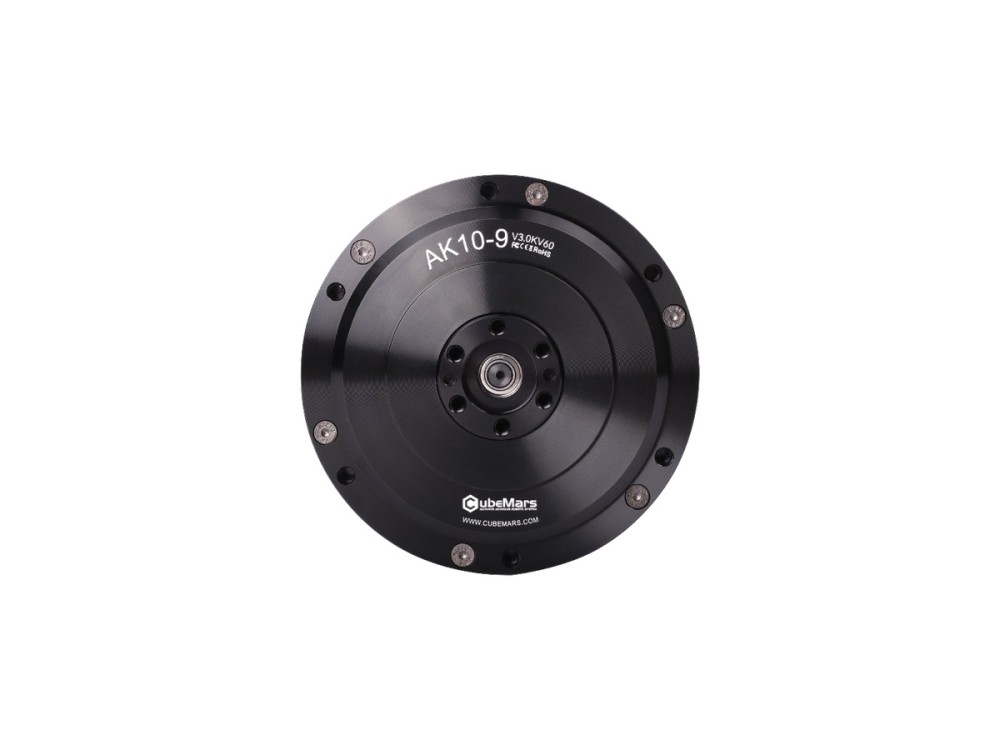
The AK10-9 V3.0 integrates a high-torque BLDC motor, 9:1 planetary gearbox and driver with dual encoders. It outputs 53 Nm peak and 18 Nm rated torque with 442 W rated power at 48 V, a proven choice for humanoid legs and robot arms.
CubeMars DW15 thruster delivers 15 kgf of thrust with 750 W rated power at 48 V in a 131 mm, 1.26 kg body. Built for demanding ROV missions, it balances thrust, efficiency and durability.
CubeMars RO80 KV105 Standard frameless motor outputs 4 Nm peak and 1.3 Nm rated torque with 490 W rated power. The 93 mm, 352 g unit runs on 48 V and provides large-torque direct drive for legged robots and industrial-grade joint modules.
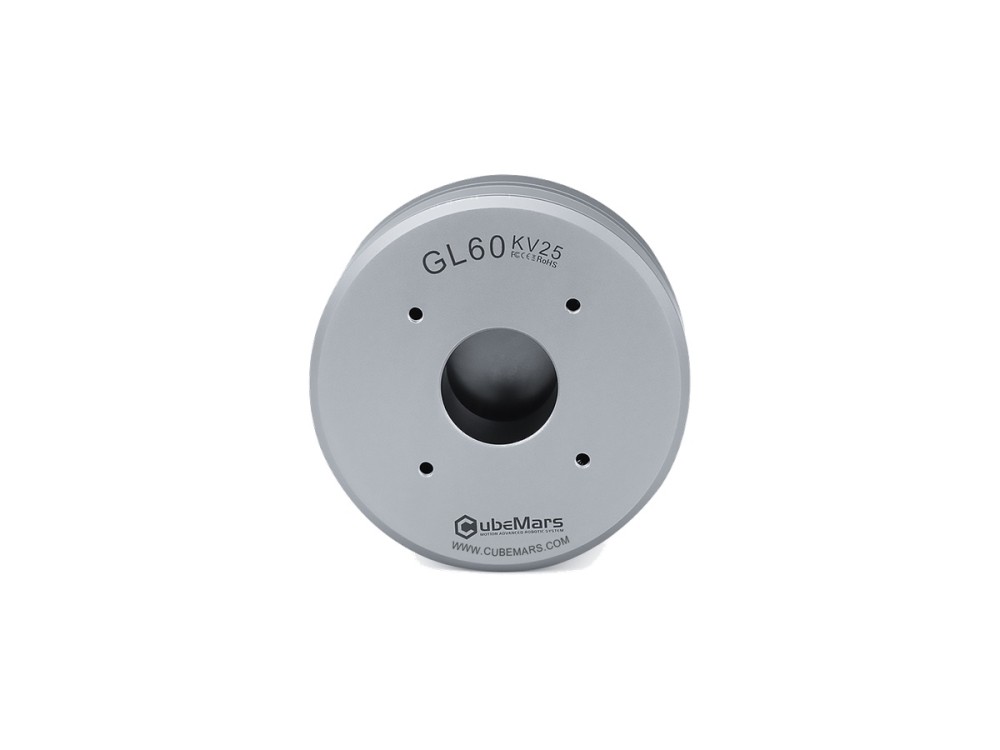
CubeMars GL60 gimbal motor produces 1.75 Nm peak and 0.6 Nm rated torque at 230 g. Its 69 mm low-cogging direct-drive design supports larger camera payloads in professional gimbal systems.
The AKE60-8 KV80 offers 12.5 Nm peak and 5 Nm rated torque via an 8:1 planetary stage at 24 V, weighing just 260 g. Its quasi-direct drive design gives low inertia and compliance for compact humanoid and exoskeleton joints.
CubeMars AKE80-8 KV30 quasi-direct drive actuator delivers 30 Nm peak and 12 Nm rated torque through an 8:1 reducer on a 48 V supply. At 570 g, its low inertia and backdrivability suit exoskeletons, rehabilitation robots and legged joints.
The CubeMars AKE40-6 KV90 quasi direct drive actuator integrates a brushless DC motor with a 6:1 planetary gearbox in a Ø51 x 24.5 mm, 140 g housing. On 24 V it delivers 50 W of continuous power, draws 2.5 A rated and 8 A peak current, reaches 260 rpm rated and 330 rpm no-load speed, and holds backlash to 9 arcmin with 0.05 N·m backdrive torque, suiting exoskeletons and lightweight robotic joints.
The CubeMars AKE50-8 KV110 quasi direct drive actuator integrates a brushless DC motor with an 8:1 planetary gearbox in a Ø61.2 x 22.5 mm, 190 g housing. On 24 V it delivers 65 W of continuous power, draws 3 A rated and 9 A peak current, reaches 240 rpm rated and 320 rpm no-load speed, and holds backlash to 9 arcmin with 0.09 N·m backdrive torque, suiting wearable devices, robotic joints and colla···
The AKE90-8 KV35 quasi-direct drive actuator combines an 8:1 planetary stage with low-inertia control, producing 170 Nm peak and 55 Nm rated torque. Weighing 1.4 kg at 48 V, it is aimed at humanoid legs, exoskeletons and high-dynamic joint modules.
Subscribe for the latest products, manufacturers and industry updates.