CubeMars GL30 KV290 Gimbal Motor
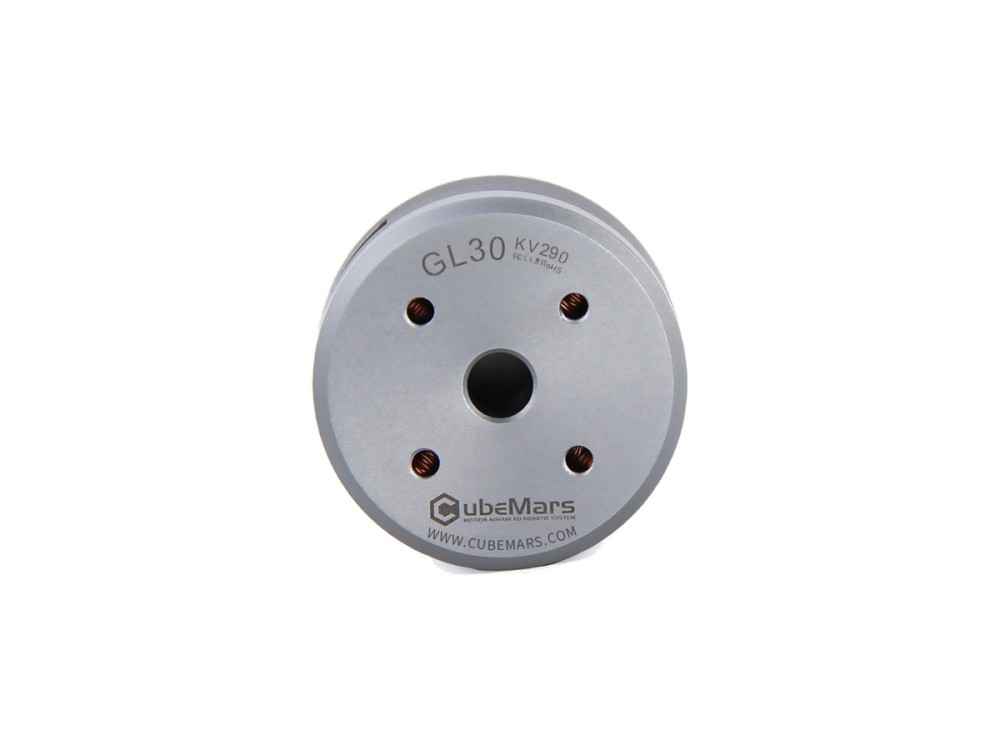
The GL30 KV290 is an ultralight 41 g gimbal motor with 0.28 Nm peak torque in a 34.5 mm frame. Designed for 12 V systems, it brings precise direct-drive stabilization to compact camera gimbals.
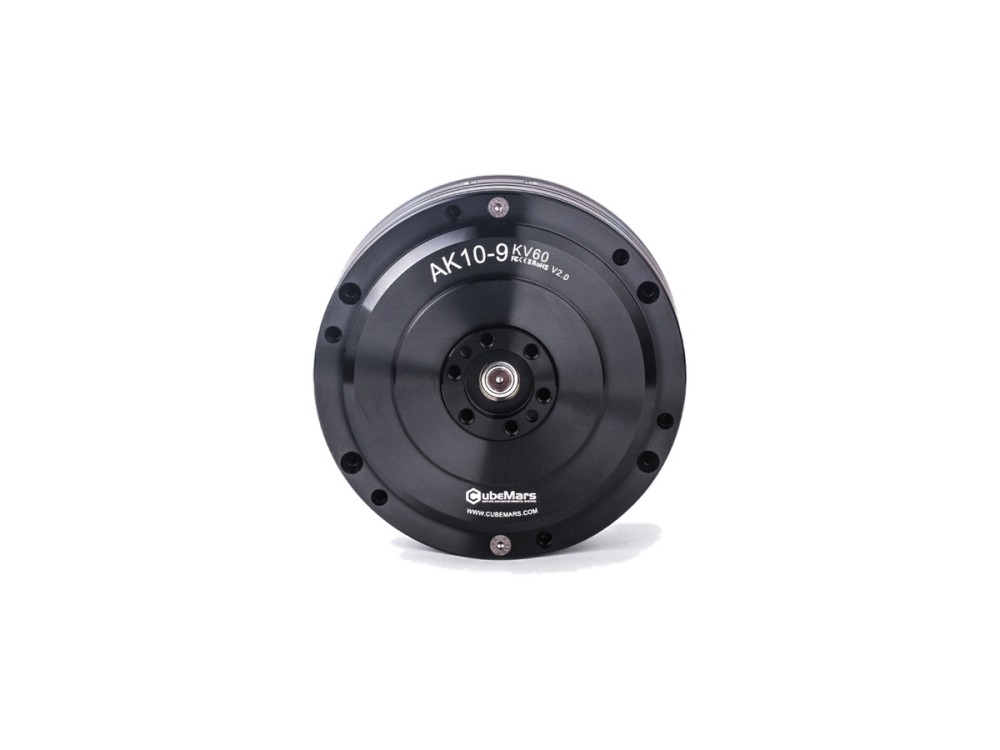
CubeMars AK10-9 V2.0 robotic actuator provides 48 Nm peak and 18 Nm rated torque via a 9:1 reducer, with dual encoders and 24/48 V flexibility. Weighing 960 g, it serves humanoid robots, exoskeletons and precision joint modules.
* Specifications are provided for reference. Please verify the latest specifications with the manufacturer.
The GL30 KV290 is an ultralight 41 g gimbal motor with 0.28 Nm peak torque in a 34.5 mm frame. Designed for 12 V systems, it brings precise direct-drive stabilization to compact camera gimbals.
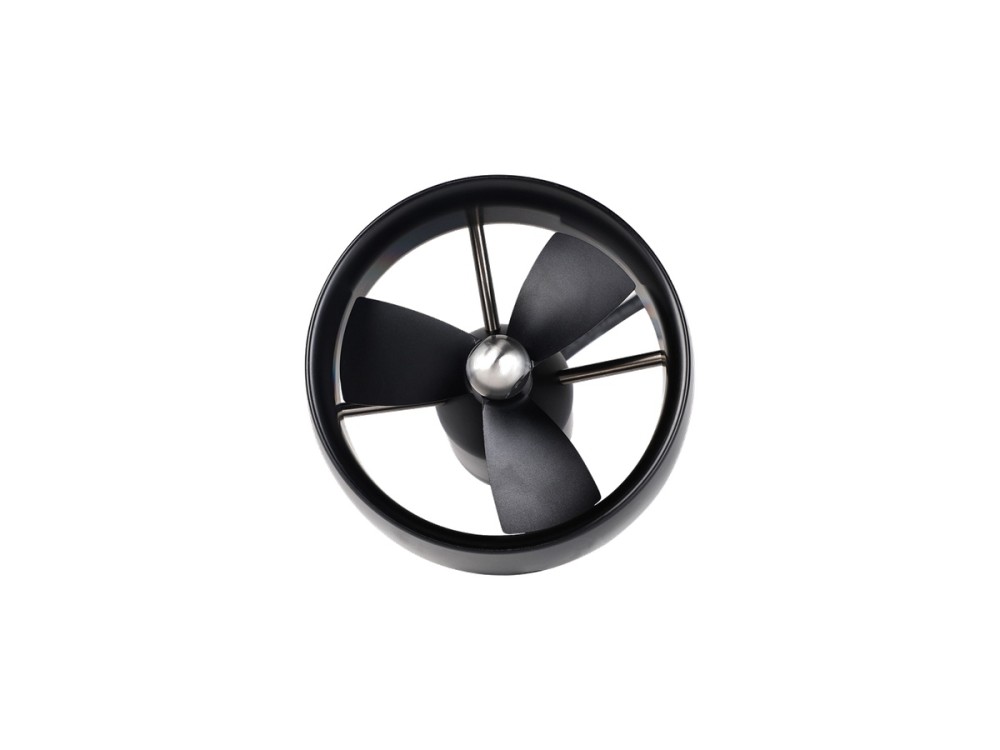
CubeMars DW25 is the flagship DW thruster with 25 kgf of thrust and 1315 W rated power at 48 V. The 1.79 kg unit provides powerful, reliable propulsion for large ROVs and heavy underwater vehicles.
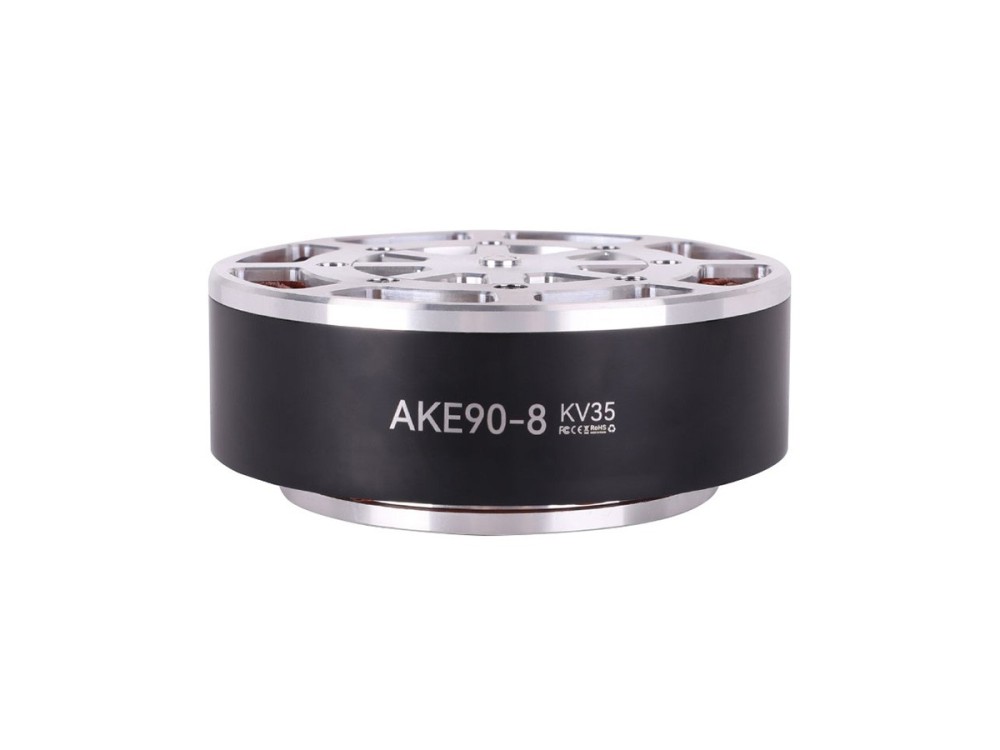
The AKE90-8 KV35 quasi-direct drive actuator combines an 8:1 planetary stage with low-inertia control, producing 170 Nm peak and 55 Nm rated torque. Weighing 1.4 kg at 48 V, it is aimed at humanoid legs, exoskeletons and high-dynamic joint modules.
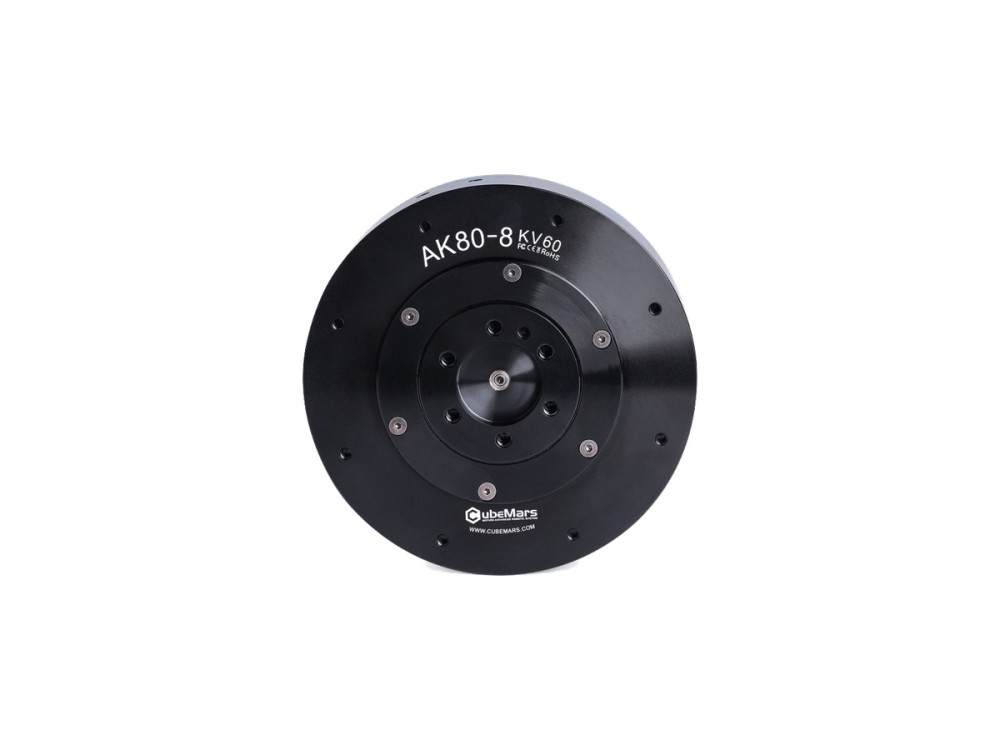
CubeMars AK80-8 actuator integrates an 8:1 reducer for 25 Nm peak and 10 Nm rated torque with 230 W rated power on a 48 V bus. The 570 g unit is widely used in exoskeletons, quadrupeds and collaborative robot joints.
The AK40-10 V3.0 is an ultralight 190 g robotic actuator integrating a BLDC motor, 10:1 planetary gearbox and driver. It provides 4.1 Nm peak and 1.3 Nm rated torque at 24 V, ideal for dexterous robotic arms and small joint modules.
The AK45-36 V3.0 pairs a KV80 motor with a 36:1 planetary reducer for 24 Nm peak and 8 Nm rated torque in a 349 g package. Running at 24 V, it is engineered for joint modules needing high reduction and precise, stable output.
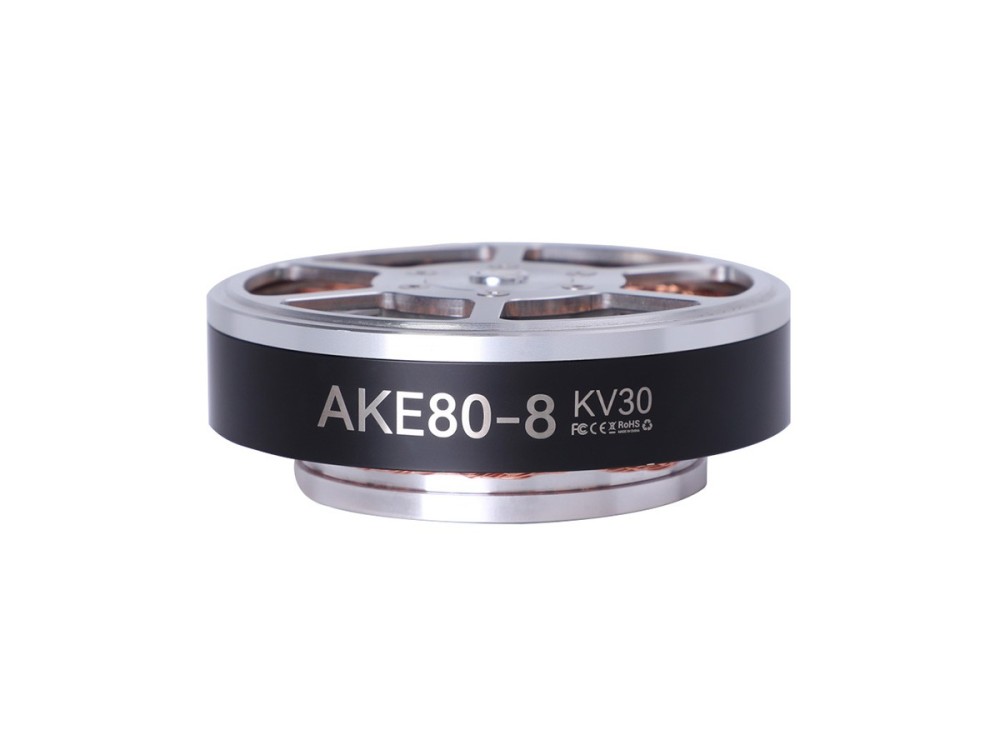
CubeMars AKE80-8 KV30 quasi-direct drive actuator delivers 30 Nm peak and 12 Nm rated torque through an 8:1 reducer on a 48 V supply. At 570 g, its low inertia and backdrivability suit exoskeletons, rehabilitation robots and legged joints.
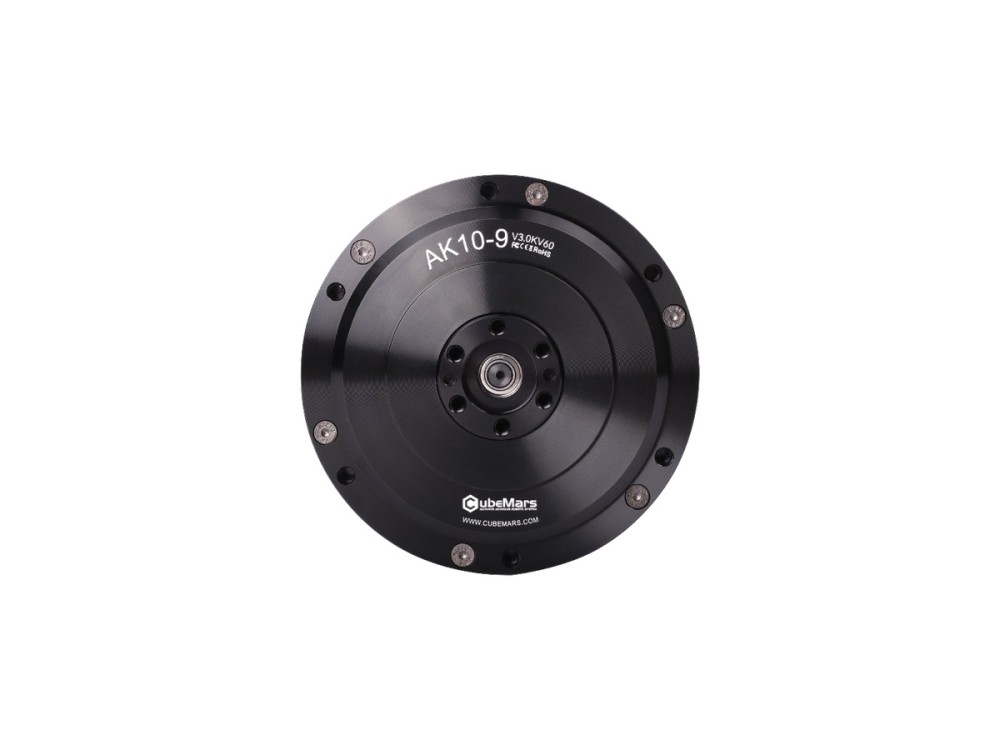
The AK10-9 V3.0 integrates a high-torque BLDC motor, 9:1 planetary gearbox and driver with dual encoders. It outputs 53 Nm peak and 18 Nm rated torque with 442 W rated power at 48 V, a proven choice for humanoid legs and robot arms.
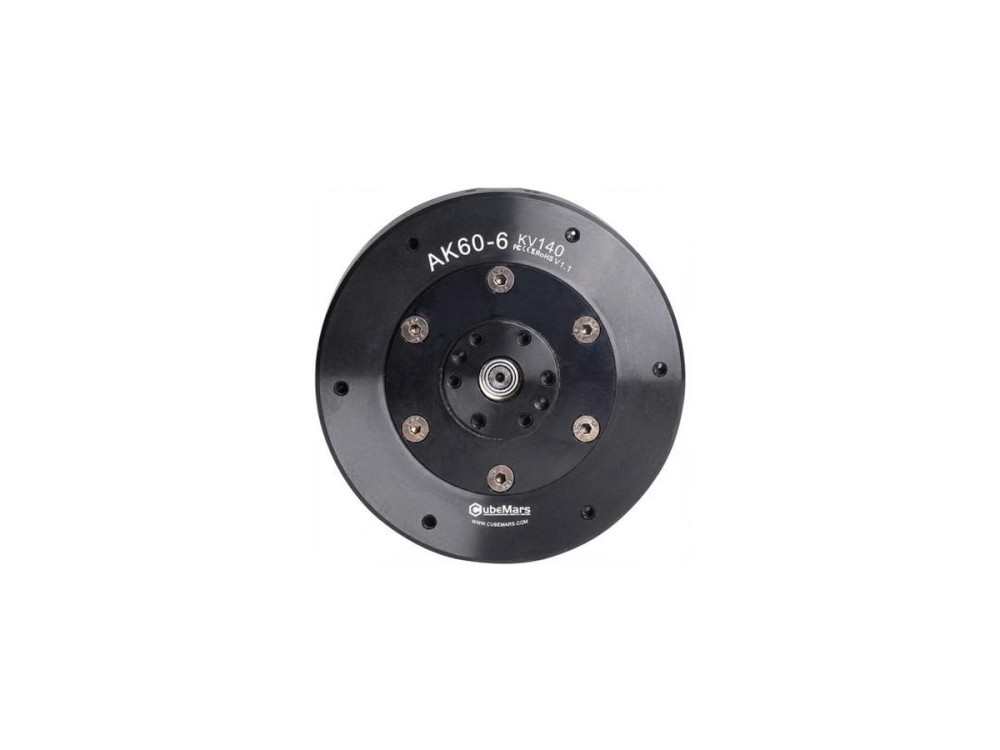
The AK60-6 V1.1 KV140 offers 9 Nm peak and 3 Nm rated torque with 130 W rated power at 24 V, reaching 560 rpm no-load. Its 368 g integrated body with 6:1 reducer fits nimble joints in desktop arms and small legged robots.
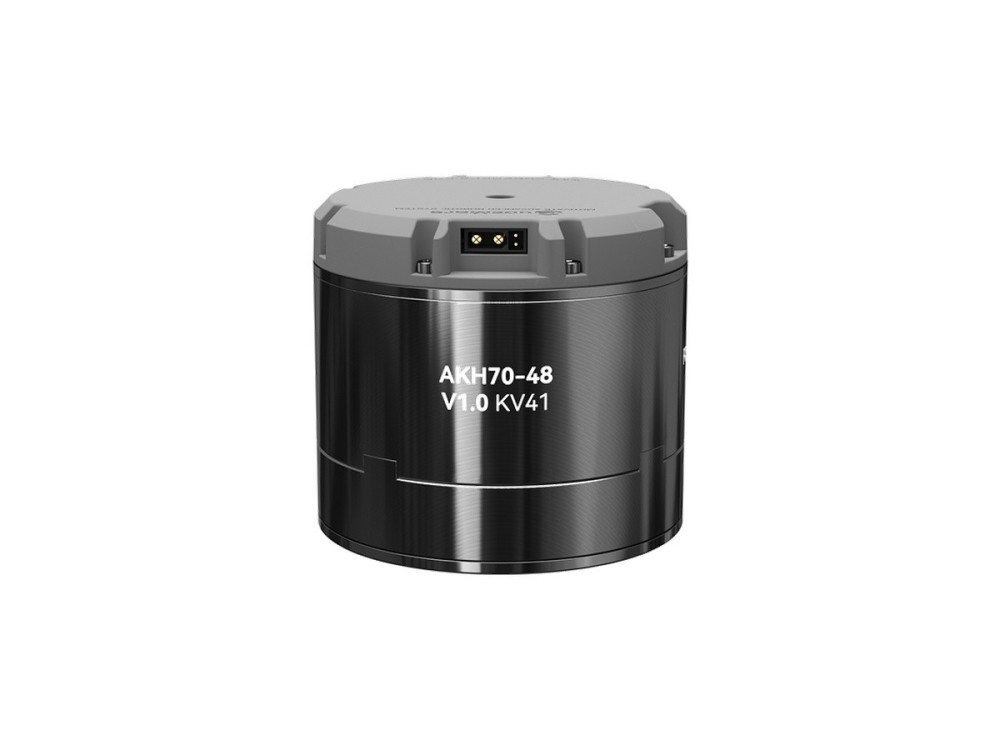
The AKH70-48 V1.0 hollow-shaft planetary actuator delivers 222 Nm peak and 74 Nm rated torque through a 48:1 reducer at 48 V. Weighing 1.4 kg with cable pass-through, it powers heavy legged robots, AGV drives and large joint modules.
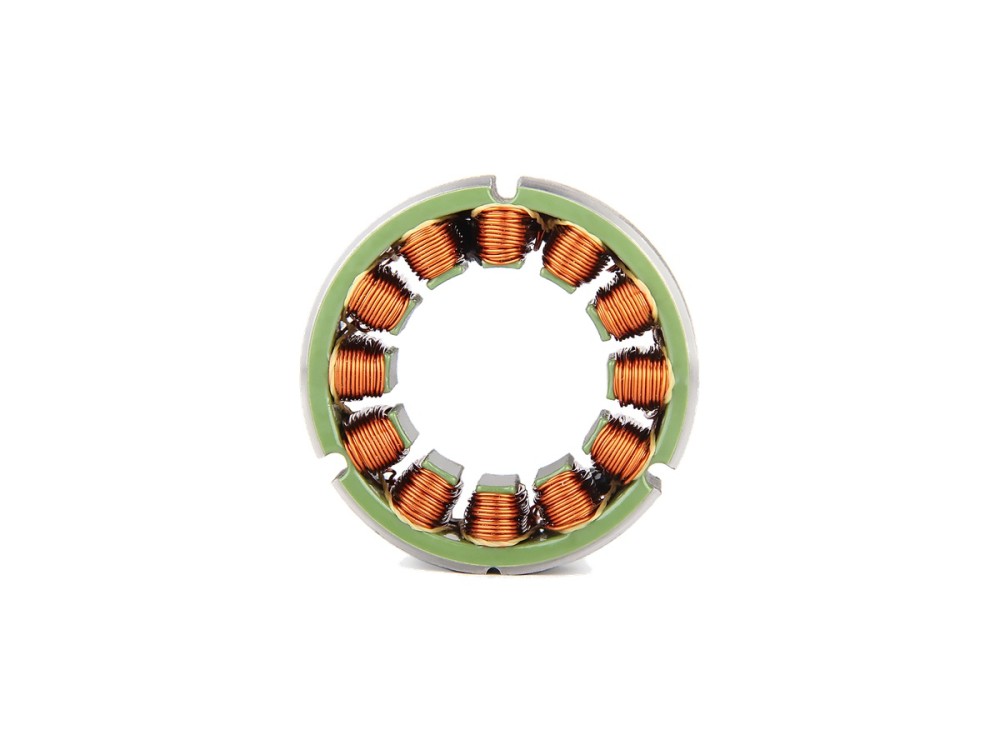
The RI50 KV100 is a frameless inrunner torque motor built for 24-48 V systems. In a 54 mm, 181 g package it produces 1.67 Nm peak and 0.58 Nm rated torque with 66 W rated power, serving quadruped robots, exoskeletons, AGVs and robotic arm joints.
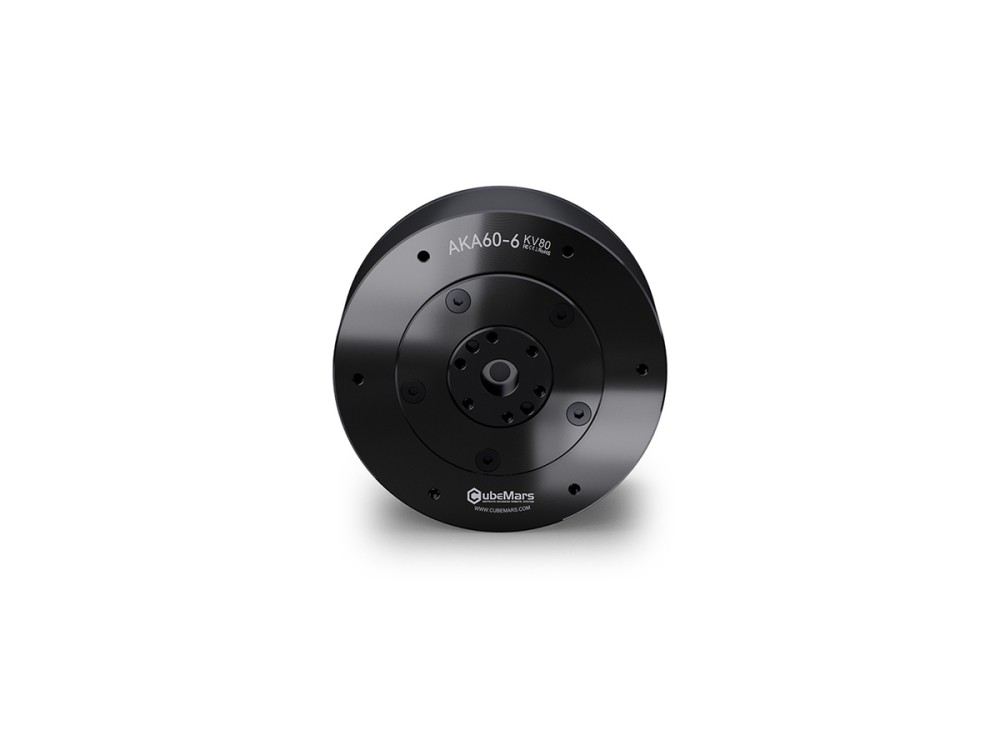
Designed for wheeled robots and AGVs, the AKA60-6 KV80 actuator provides 9 Nm peak and 3 Nm rated torque through a 6:1 reducer with reinforced radial load capacity. It weighs 460 g, runs on 24/48 V and outputs 62 W rated power.

Which CubeMars robotic actuators accept a 48 V bus, what the higher voltage chan···

BLDC motors for a quadruped robot leg: how stance duty sets continuous torque, h···
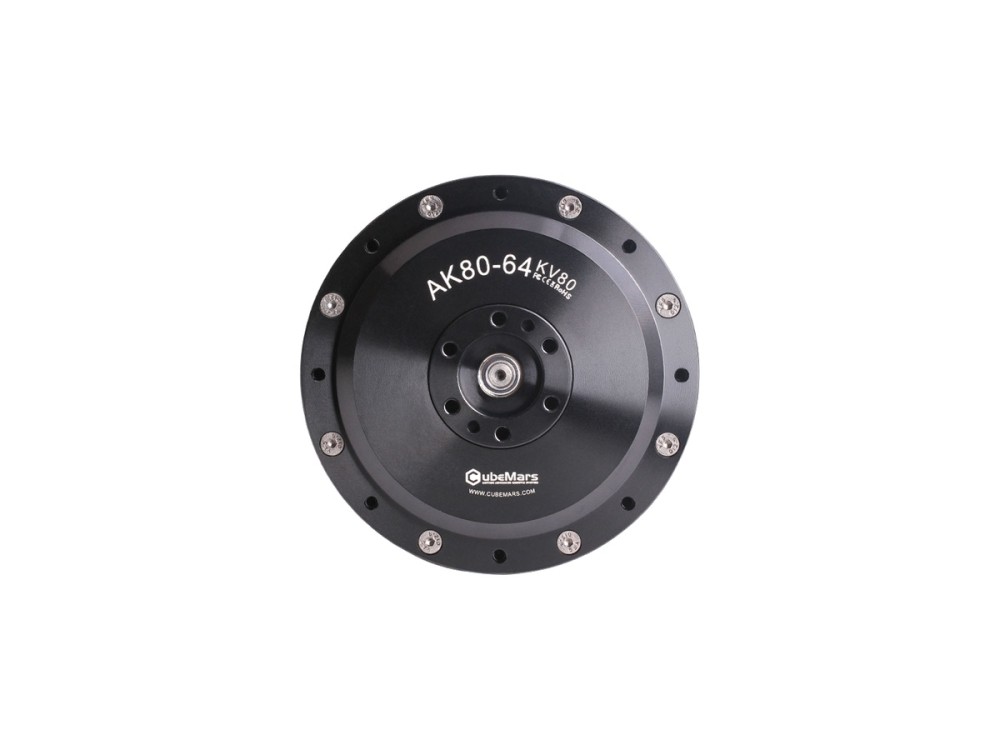
CubeMars AK80-64 actuator mounts a KV80 motor on a 64:1 planetary reducer, producing 120 Nm peak and 48 Nm rated torque in an 850 g body. Accepting 24/48 V, it targets high-load joints on legged robots and heavy manipulators.
Designed for wheeled robots and AGVs, the AKA60-6 KV80 actuator provides 9 Nm peak and 3 Nm rated torque through a 6:1 reducer with reinforced radial load capacity. It weighs 460 g, runs on 24/48 V and outputs 62 W rated power.
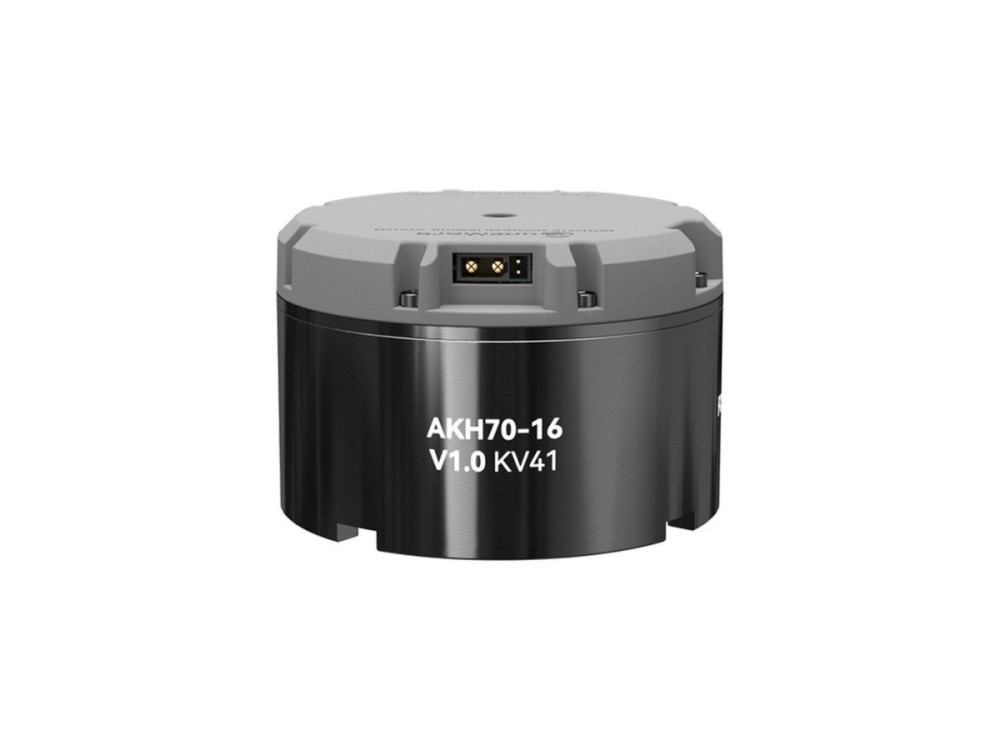
CubeMars AKH70-16 V1.0 combines a hollow shaft with a 16:1 planetary stage for 78 Nm peak and 26 Nm rated torque. The 879 g actuator runs on 48 V and fits quadruped knees, robotic arm joints and wheeled drives needing internal cable routing.
CubeMars AK80-8 actuator integrates an 8:1 reducer for 25 Nm peak and 10 Nm rated torque with 230 W rated power on a 48 V bus. The 570 g unit is widely used in exoskeletons, quadrupeds and collaborative robot joints.
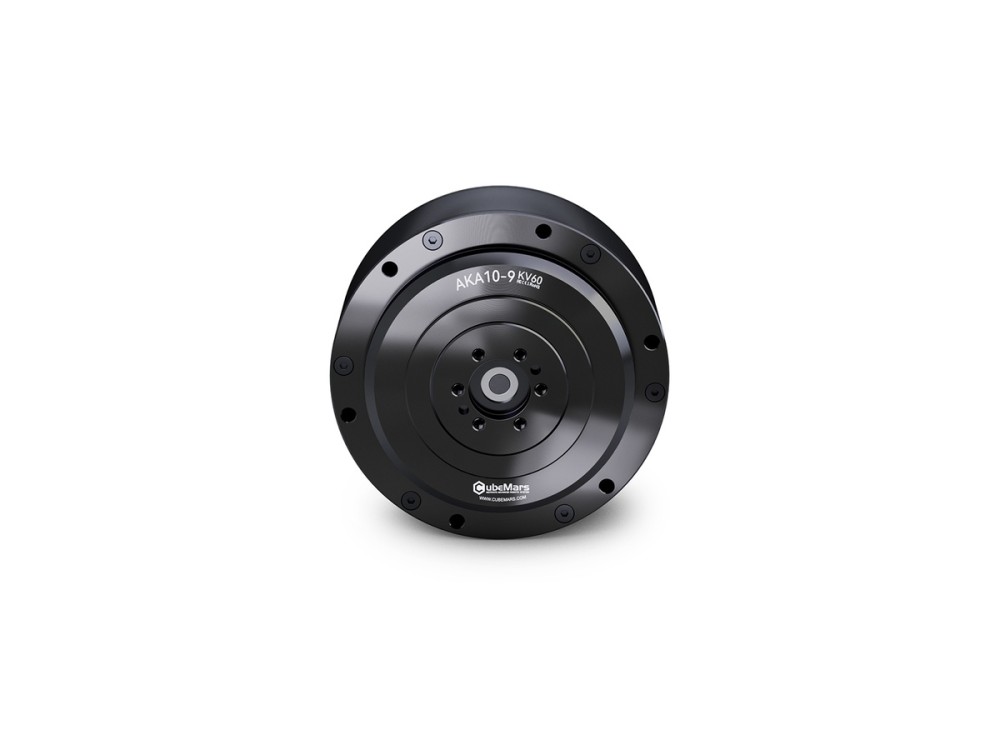
The AKA10-9 KV60 is a wheel-drive actuator for AGVs and wheeled robots, delivering 53 Nm peak and 18 Nm rated torque with 120 percent higher radial load capacity. Its 9:1 reducer, single 16-bit magnetic encoder and 48 V, 205 W rated power ensure robust traction.
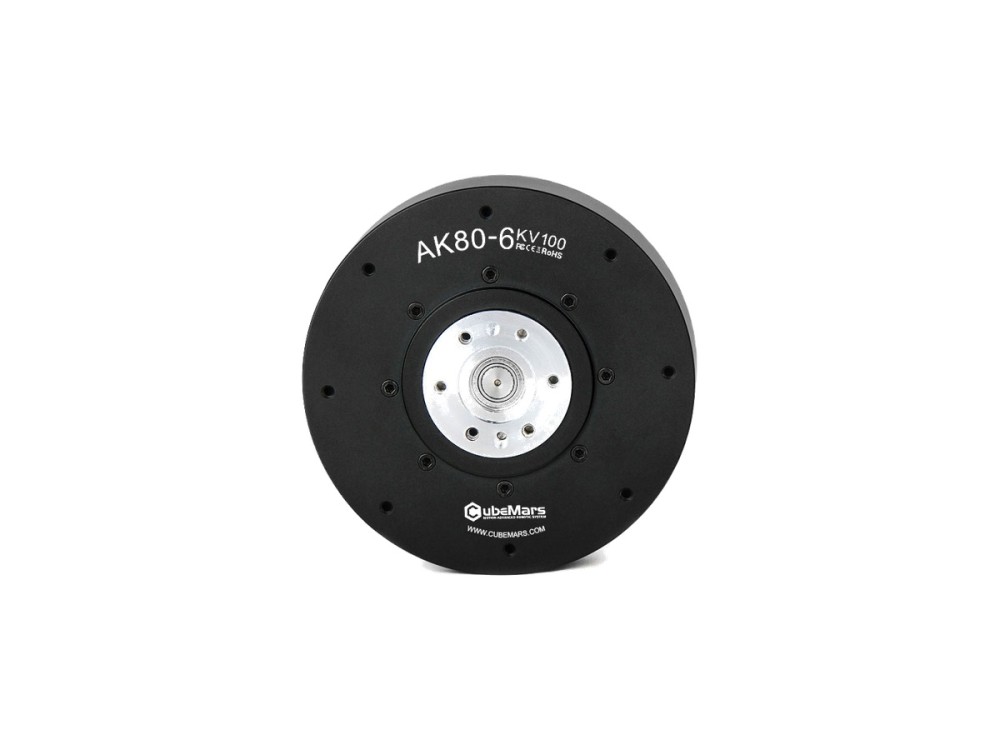
The AK80-6 V1.0 uses a 6:1 reduction for 12 Nm peak and 6 Nm rated torque, reaching 800 rpm no-load with 340 W rated power. Weighing 485 g at 48 V, it favors faster joints in humanoid arms and light quadruped robots.
CubeMars AK45-10 V3.0 actuator delivers 7 Nm peak and 2.5 Nm rated torque through a 10:1 reducer, weighing 262 g at 53 mm diameter. Rated 39 W on a 24 V bus, it suits compact robot joints and rehabilitation exoskeletons.
The AK10-9 V3.0 integrates a high-torque BLDC motor, 9:1 planetary gearbox and driver with dual encoders. It outputs 53 Nm peak and 18 Nm rated torque with 442 W rated power at 48 V, a proven choice for humanoid legs and robot arms.
The AKH70-48 V1.0 hollow-shaft planetary actuator delivers 222 Nm peak and 74 Nm rated torque through a 48:1 reducer at 48 V. Weighing 1.4 kg with cable pass-through, it powers heavy legged robots, AGV drives and large joint modules.
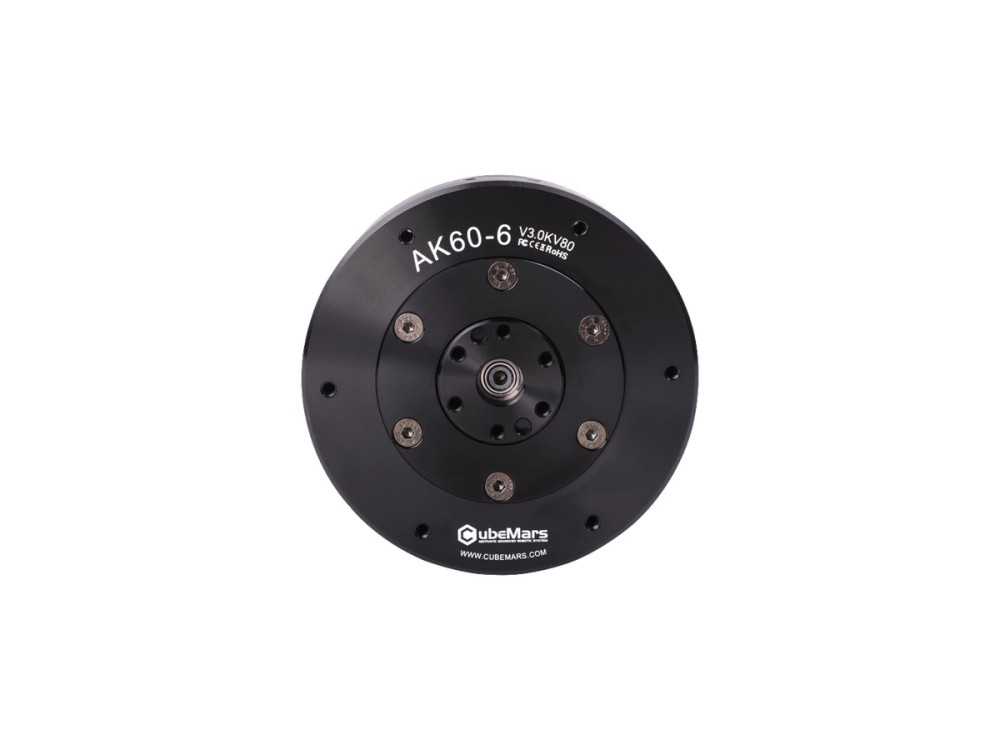
CubeMars AK60-6 V3.0 actuator delivers 9 Nm peak and 3 Nm rated torque through a compact 6:1 stage with 74 W rated power on 24/48 V. At 380 g and 79 mm, it serves light robotic arms, small joint modules and compact quadrupeds.
CubeMars AK10-9 V2.0 robotic actuator provides 48 Nm peak and 18 Nm rated torque via a 9:1 reducer, with dual encoders and 24/48 V flexibility. Weighing 960 g, it serves humanoid robots, exoskeletons and precision joint modules.
The AK40-10 V3.0 is an ultralight 190 g robotic actuator integrating a BLDC motor, 10:1 planetary gearbox and driver. It provides 4.1 Nm peak and 1.3 Nm rated torque at 24 V, ideal for dexterous robotic arms and small joint modules.
Subscribe for the latest products, manufacturers and industry updates.