CubeMars DW10 Underwater Thruster
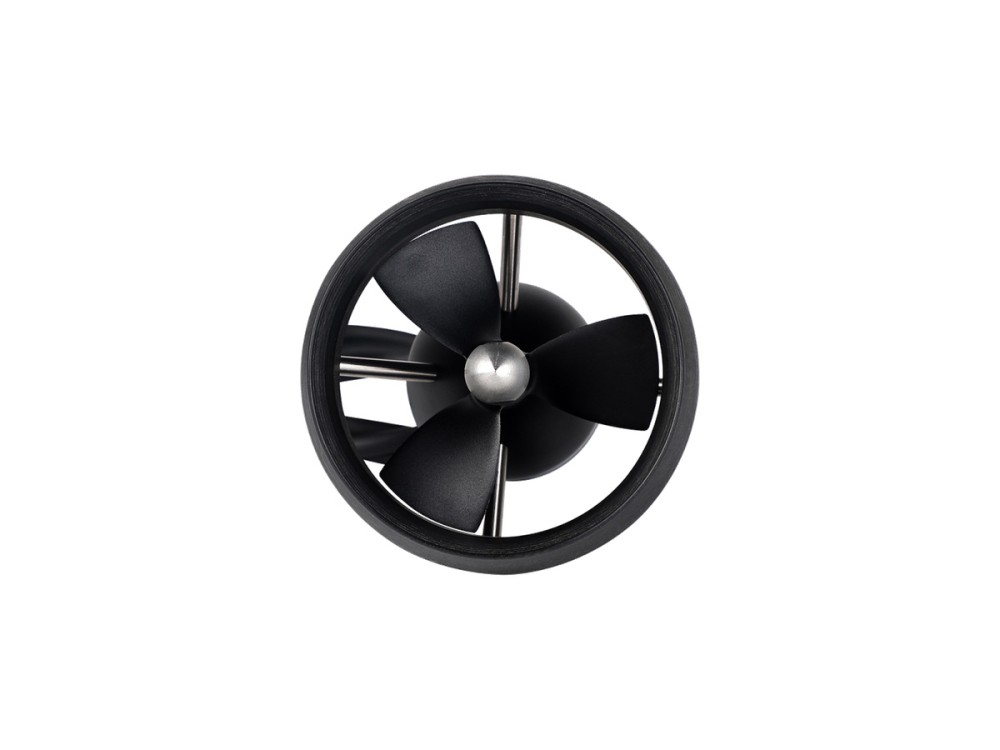
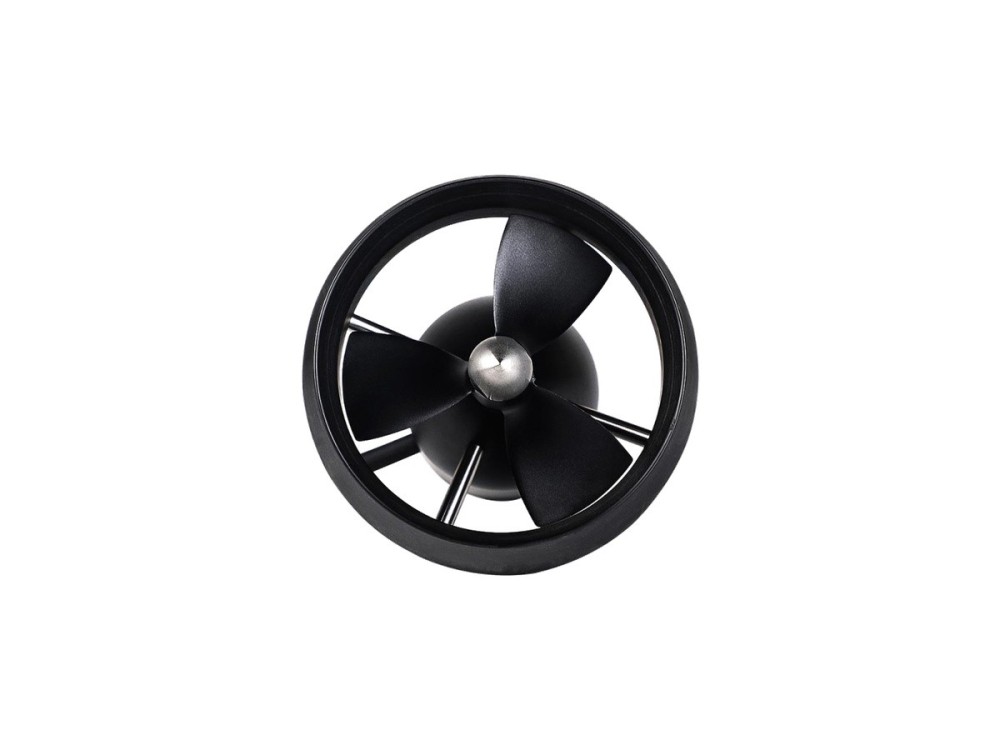
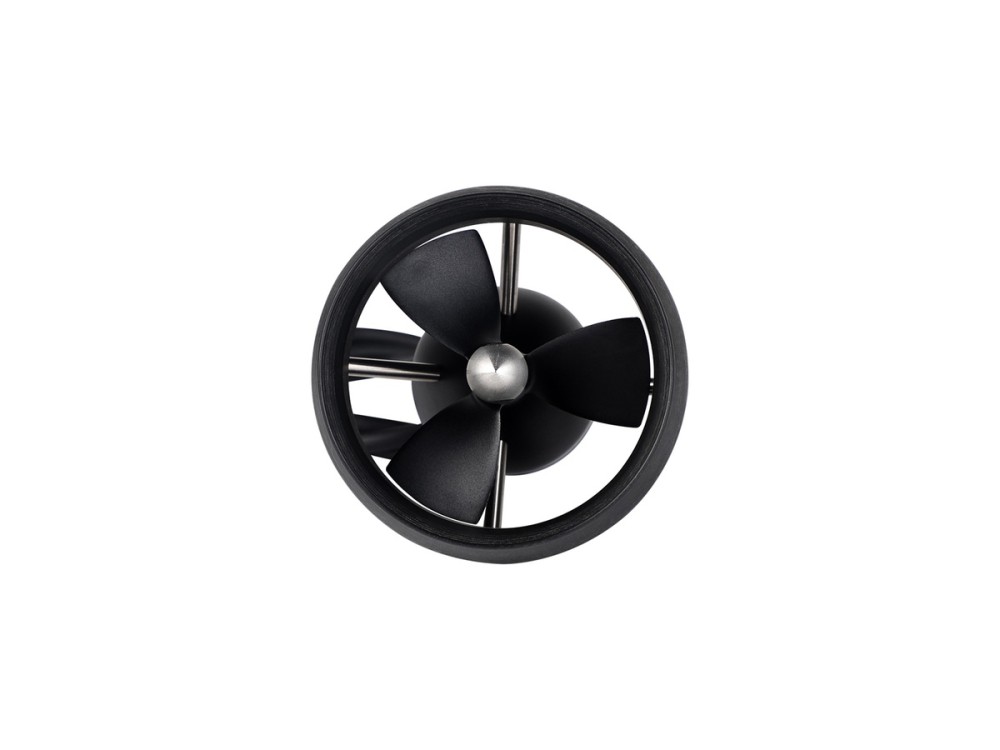
The DW10 underwater thruster provides 10 kgf of thrust with 540 W rated power at 36 V in a 100 mm, 840 g housing. Efficient and low noise, it suits ROV maneuvering and small underwater vehicles.
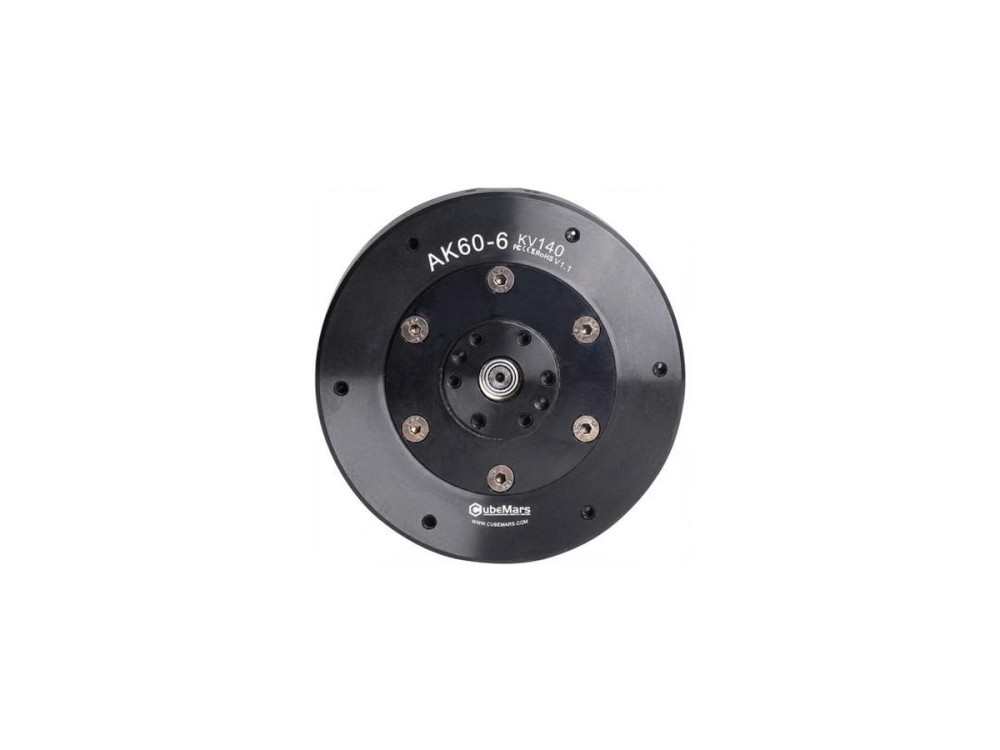
The AK60-6 V1.1 KV140 offers 9 Nm peak and 3 Nm rated torque with 130 W rated power at 24 V, reaching 560 rpm no-load. Its 368 g integrated body with 6:1 reducer fits nimble joints in desktop arms and small legged robots.
* Specifications are provided for reference. Please verify the latest specifications with the manufacturer.
The DW10 underwater thruster provides 10 kgf of thrust with 540 W rated power at 36 V in a 100 mm, 840 g housing. Efficient and low noise, it suits ROV maneuvering and small underwater vehicles.
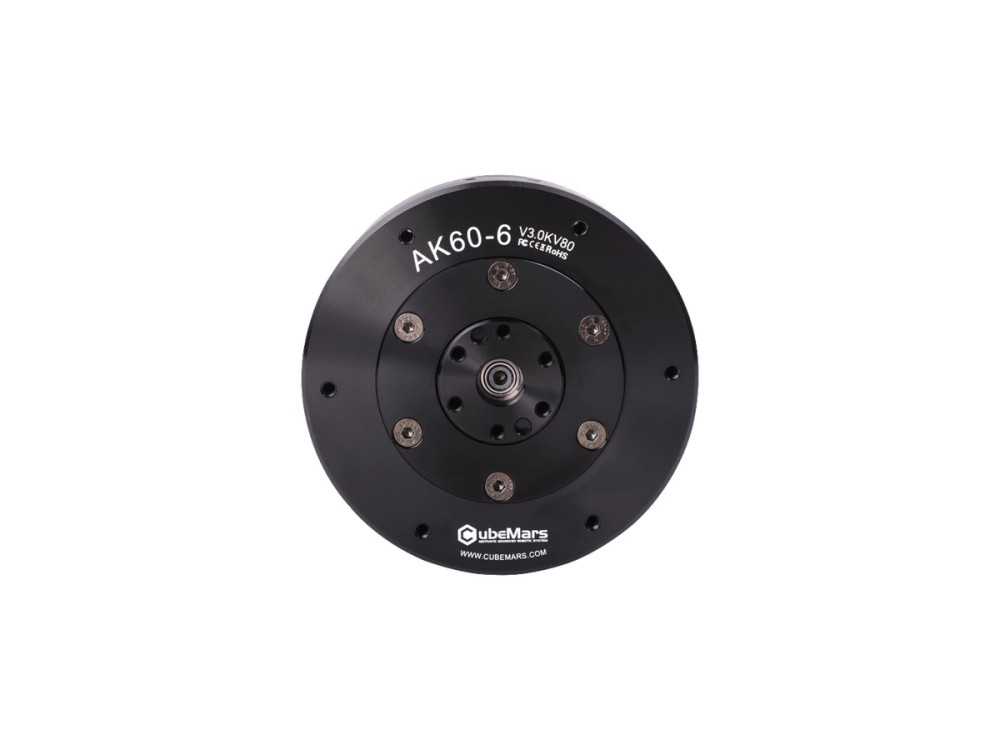
CubeMars AK60-6 V3.0 actuator delivers 9 Nm peak and 3 Nm rated torque through a compact 6:1 stage with 74 W rated power on 24/48 V. At 380 g and 79 mm, it serves light robotic arms, small joint modules and compact quadrupeds.
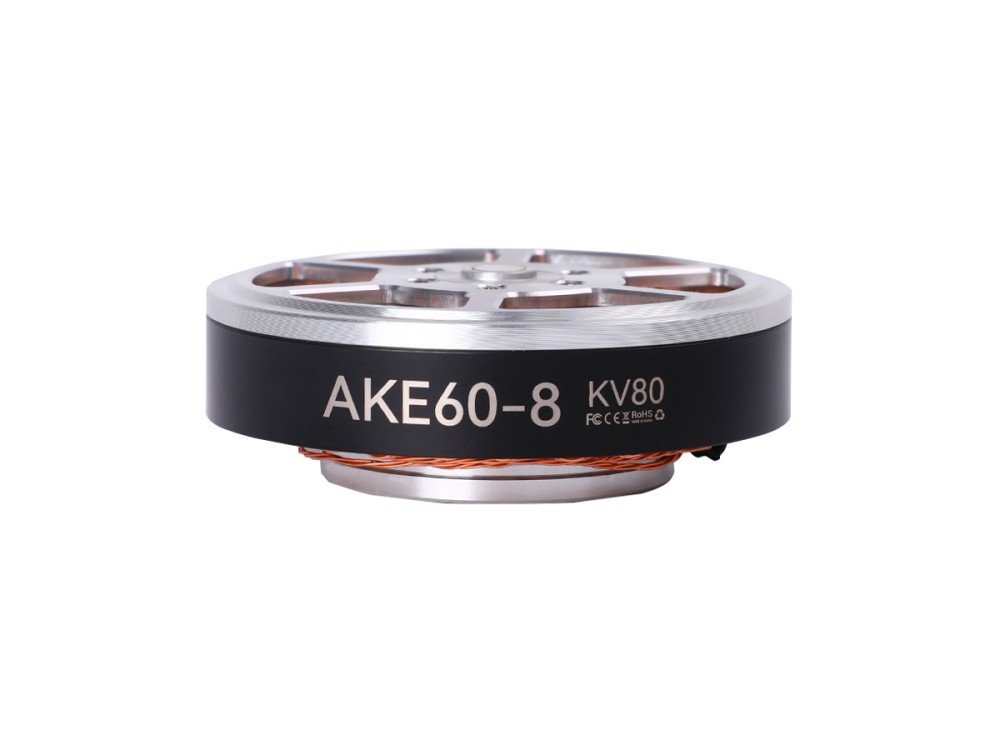
The AKE60-8 KV80 offers 12.5 Nm peak and 5 Nm rated torque via an 8:1 planetary stage at 24 V, weighing just 260 g. Its quasi-direct drive design gives low inertia and compliance for compact humanoid and exoskeleton joints.
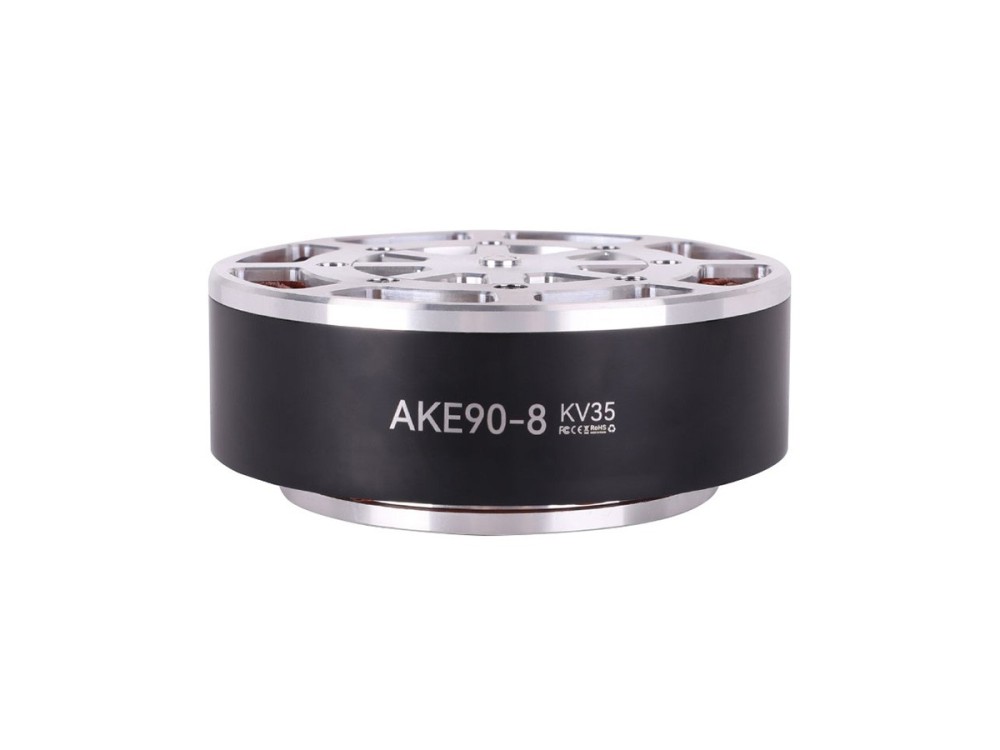
The AKE90-8 KV35 quasi-direct drive actuator combines an 8:1 planetary stage with low-inertia control, producing 170 Nm peak and 55 Nm rated torque. Weighing 1.4 kg at 48 V, it is aimed at humanoid legs, exoskeletons and high-dynamic joint modules.
The RI70 KV95 offers 2.68 Nm peak and 0.94 Nm rated torque with 125 W rated power in a 76 mm frameless inrunner body of 270 g. Designed for 24-48 V buses, it targets legged robots, joint modules and precision robotic arms.
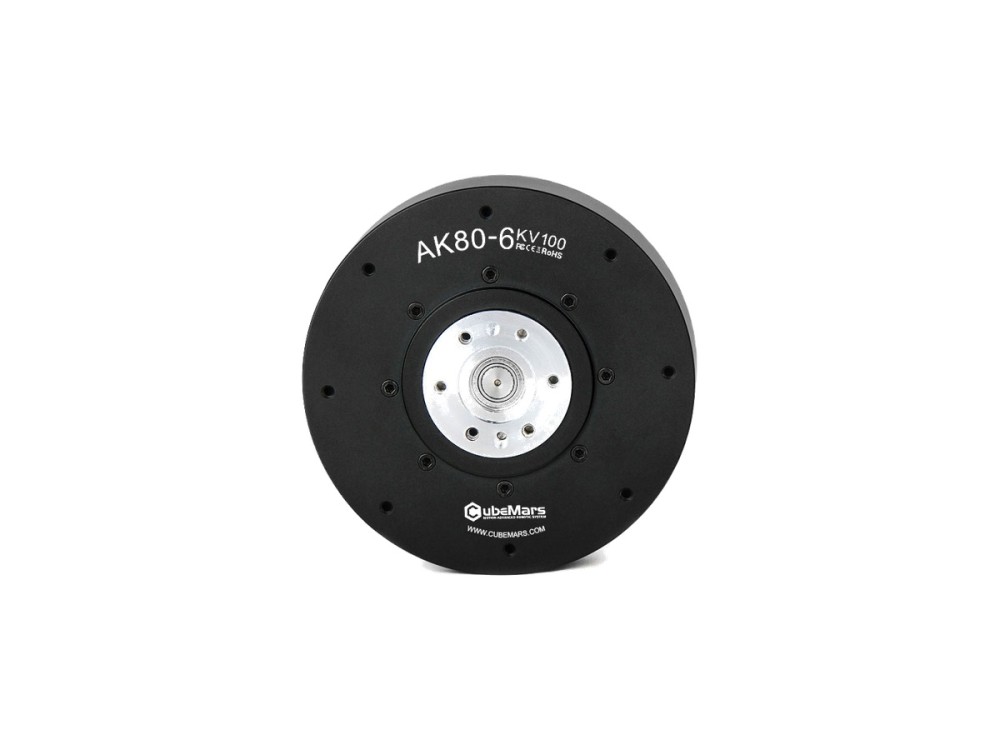
The AK80-6 V1.0 uses a 6:1 reduction for 12 Nm peak and 6 Nm rated torque, reaching 800 rpm no-load with 340 W rated power. Weighing 485 g at 48 V, it favors faster joints in humanoid arms and light quadruped robots.
CubeMars RO80 KV105 Standard frameless motor outputs 4 Nm peak and 1.3 Nm rated torque with 490 W rated power. The 93 mm, 352 g unit runs on 48 V and provides large-torque direct drive for legged robots and industrial-grade joint modules.
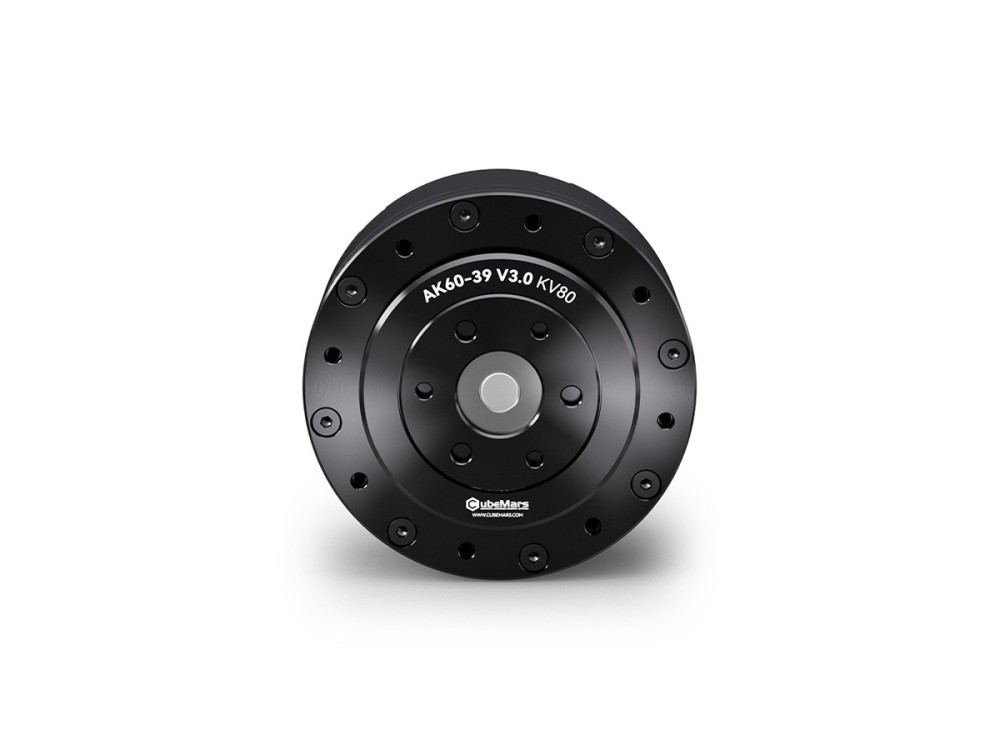
The AK60-39 V3.0 pairs a KV80 motor with a 39:1 reducer for 72 Nm peak and 24 Nm rated torque, with 176 W rated power at 48 V. Weighing 750 g, it is built for load-bearing joints in legged robots and industrial manipulators.
CubeMars DW15 thruster delivers 15 kgf of thrust with 750 W rated power at 48 V in a 131 mm, 1.26 kg body. Built for demanding ROV missions, it balances thrust, efficiency and durability.
The CubeMars SW7 underwater thruster produces over 7 kgf of thrust with 360 W rated power at 36 V in a compact 700 g body. An optimized propeller and sealing design make it a reliable propulsion choice for small ROVs and AUVs.
The RI100 KV105 is the largest RI inrunner, delivering 4.95 Nm peak and 1.76 Nm rated torque with 252 W rated power. Its 104 mm, 500 g frameless design on a 24-48 V bus serves humanoid robots, exoskeletons and high-load joint modules.
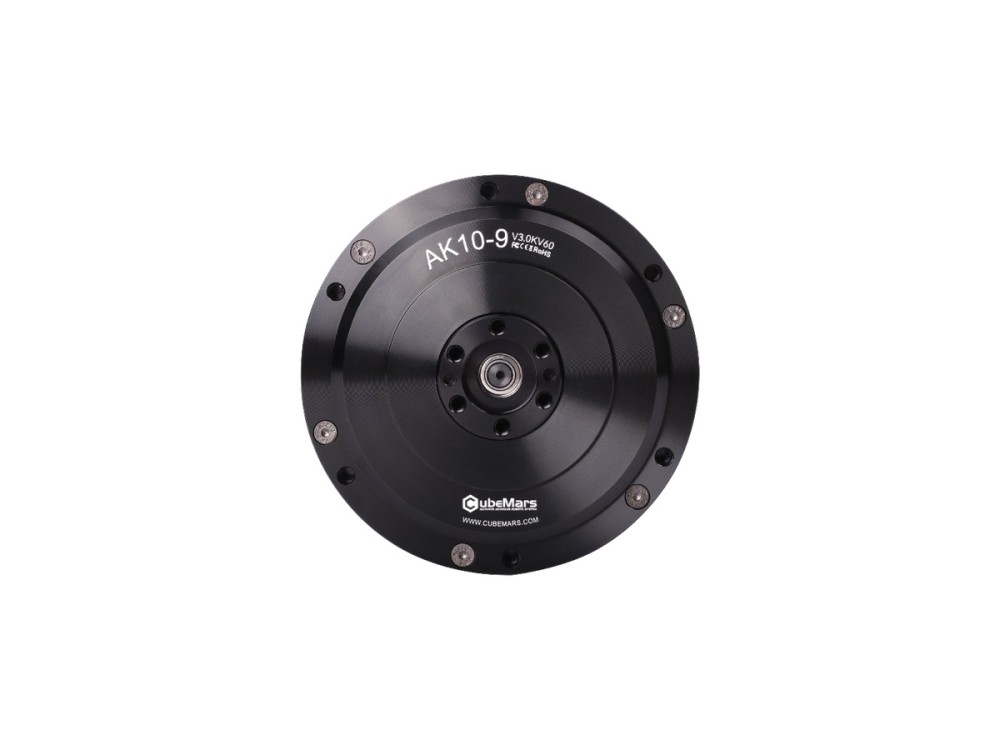
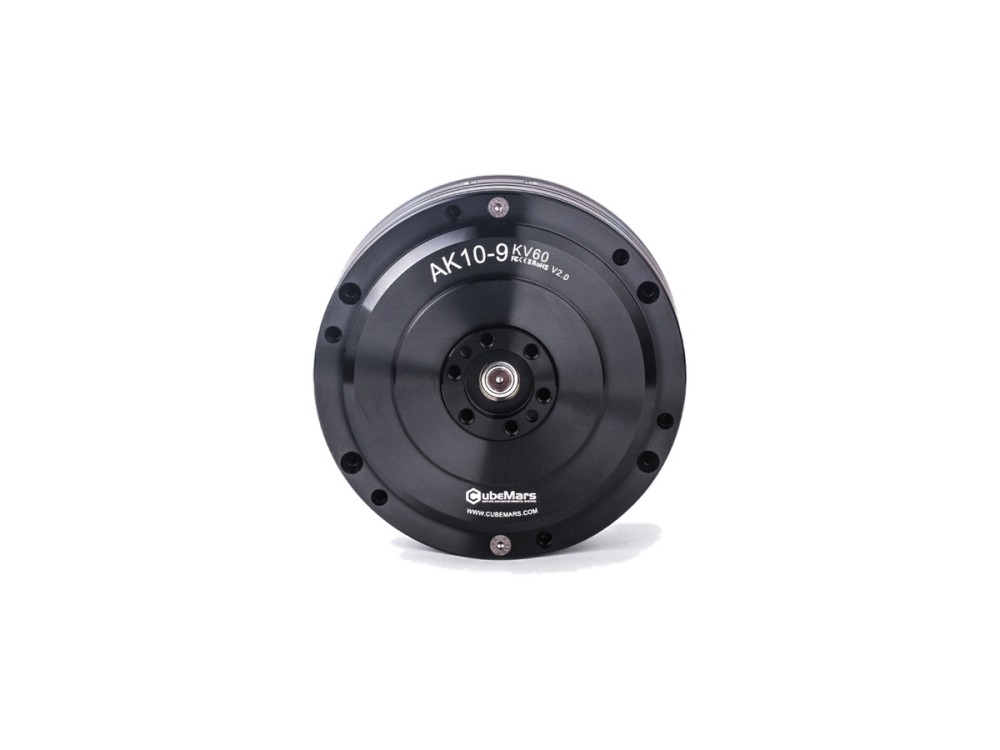
The AK10-9 V3.0 integrates a high-torque BLDC motor, 9:1 planetary gearbox and driver with dual encoders. It outputs 53 Nm peak and 18 Nm rated torque with 442 W rated power at 48 V, a proven choice for humanoid legs and robot arms.
CubeMars AK10-9 V2.0 robotic actuator provides 48 Nm peak and 18 Nm rated torque via a 9:1 reducer, with dual encoders and 24/48 V flexibility. Weighing 960 g, it serves humanoid robots, exoskeletons and precision joint modules.
The AK45-36 V3.0 pairs a KV80 motor with a 36:1 planetary reducer for 24 Nm peak and 8 Nm rated torque in a 349 g package. Running at 24 V, it is engineered for joint modules needing high reduction and precise, stable output.
The AK80-6 V1.0 uses a 6:1 reduction for 12 Nm peak and 6 Nm rated torque, reaching 800 rpm no-load with 340 W rated power. Weighing 485 g at 48 V, it favors faster joints in humanoid arms and light quadruped robots.
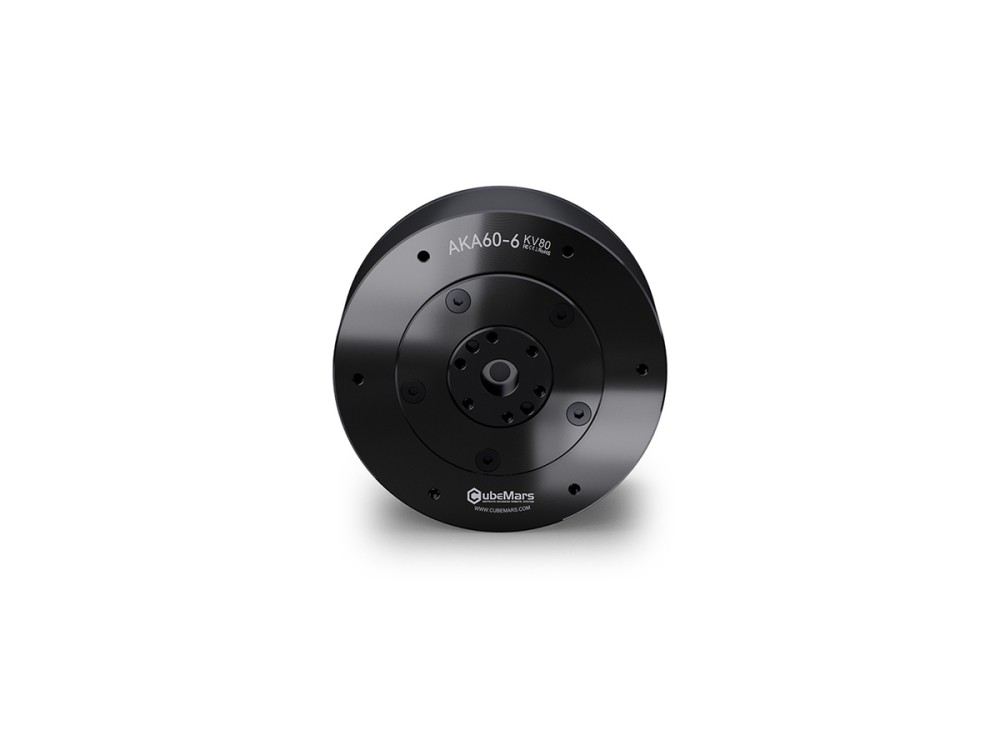
Designed for wheeled robots and AGVs, the AKA60-6 KV80 actuator provides 9 Nm peak and 3 Nm rated torque through a 6:1 reducer with reinforced radial load capacity. It weighs 460 g, runs on 24/48 V and outputs 62 W rated power.
The AK60-6 V1.1 KV140 offers 9 Nm peak and 3 Nm rated torque with 130 W rated power at 24 V, reaching 560 rpm no-load. Its 368 g integrated body with 6:1 reducer fits nimble joints in desktop arms and small legged robots.
CubeMars AK45-10 V3.0 actuator delivers 7 Nm peak and 2.5 Nm rated torque through a 10:1 reducer, weighing 262 g at 53 mm diameter. Rated 39 W on a 24 V bus, it suits compact robot joints and rehabilitation exoskeletons.
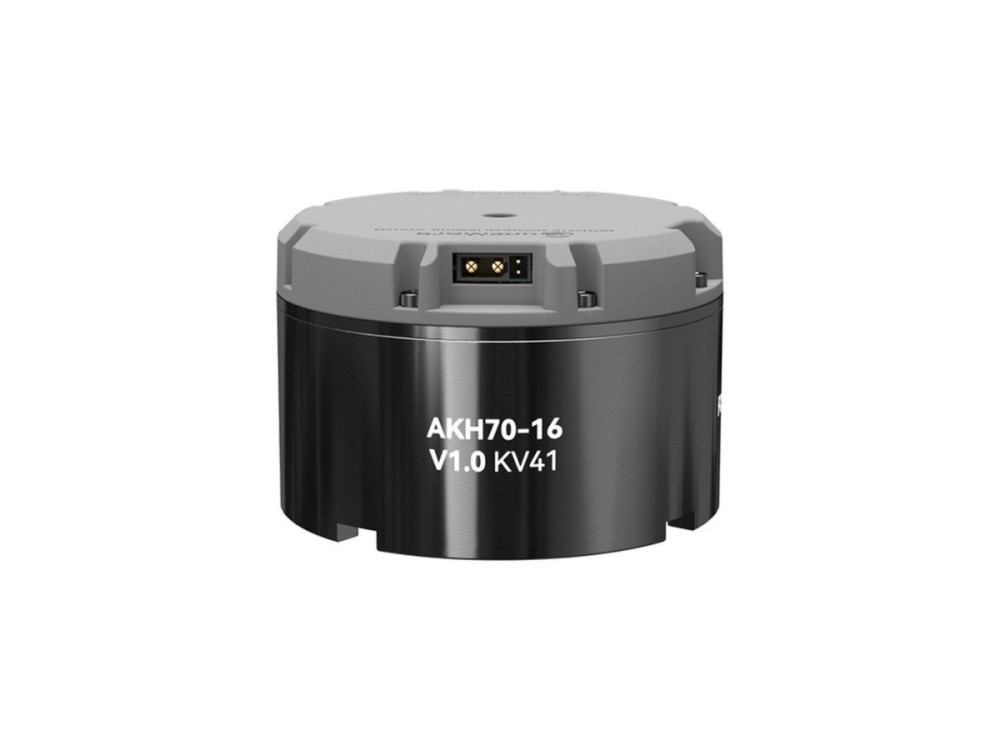
CubeMars AKH70-16 V1.0 combines a hollow shaft with a 16:1 planetary stage for 78 Nm peak and 26 Nm rated torque. The 879 g actuator runs on 48 V and fits quadruped knees, robotic arm joints and wheeled drives needing internal cable routing.
The AK10-9 V3.0 integrates a high-torque BLDC motor, 9:1 planetary gearbox and driver with dual encoders. It outputs 53 Nm peak and 18 Nm rated torque with 442 W rated power at 48 V, a proven choice for humanoid legs and robot arms.
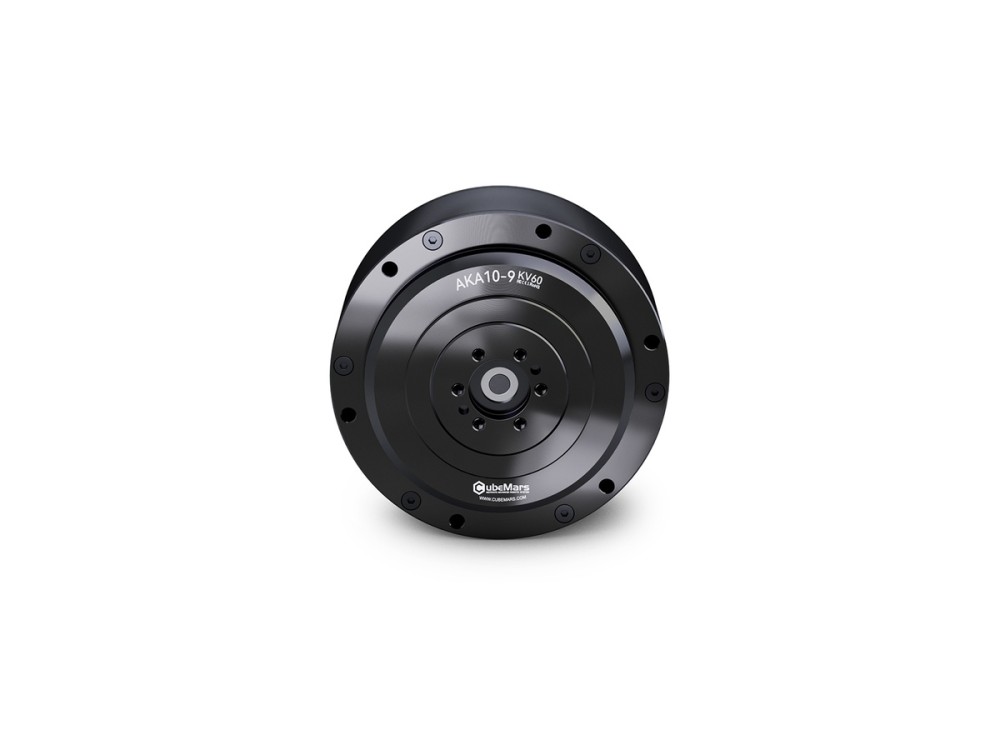
The AKA10-9 KV60 is a wheel-drive actuator for AGVs and wheeled robots, delivering 53 Nm peak and 18 Nm rated torque with 120 percent higher radial load capacity. Its 9:1 reducer, single 16-bit magnetic encoder and 48 V, 205 W rated power ensure robust traction.
CubeMars AK60-6 V3.0 actuator delivers 9 Nm peak and 3 Nm rated torque through a compact 6:1 stage with 74 W rated power on 24/48 V. At 380 g and 79 mm, it serves light robotic arms, small joint modules and compact quadrupeds.
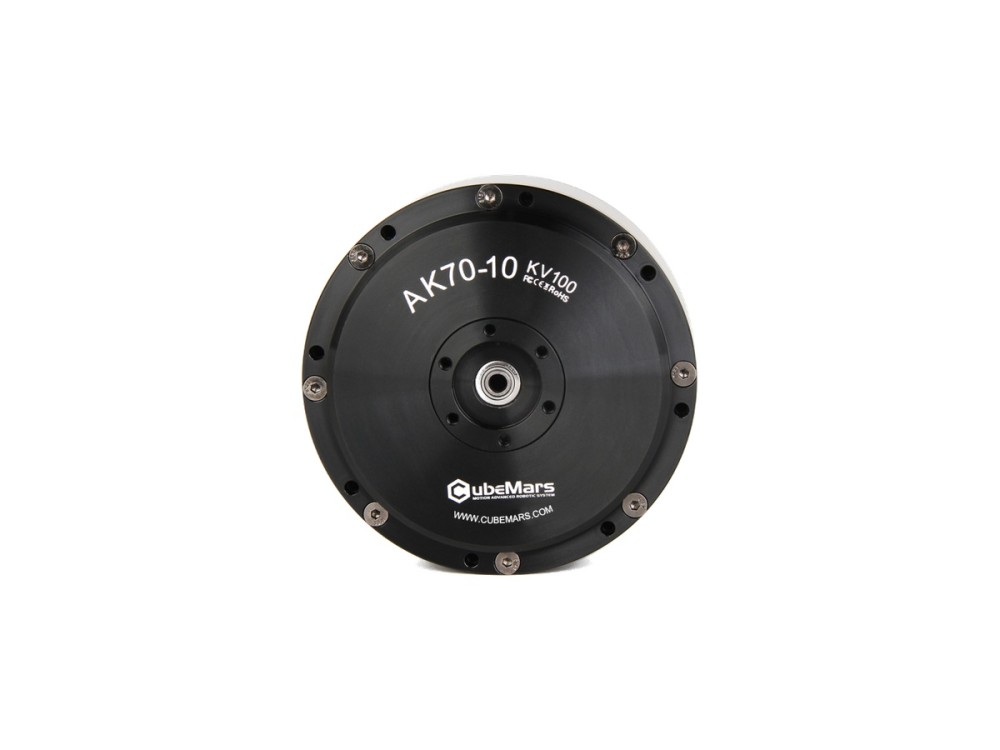
The AK70-10 pairs a 10:1 planetary stage with a single 14-bit magnetic encoder, delivering 24.8 Nm peak and 8.3 Nm rated torque plus 230 W rated power. The 621 g actuator runs on 24/48 V and suits exoskeleton joints, quadrupeds and robot arms.
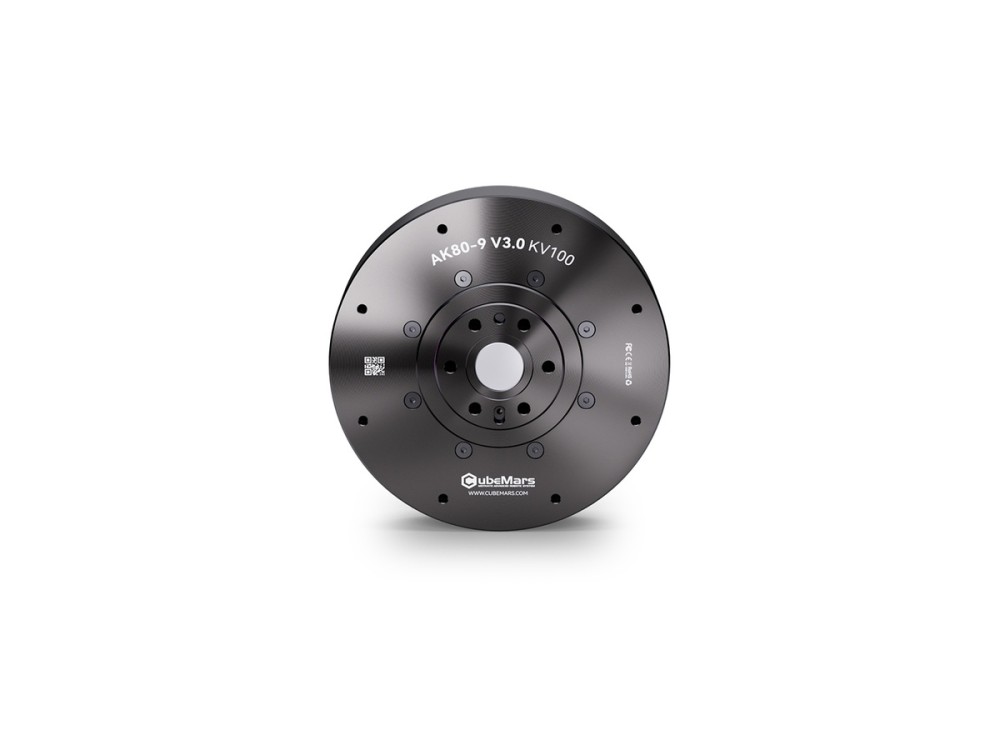
The AK80-9 V3.0 packs a BLDC motor, 9:1 planetary gearbox and driver into a 98 mm, 490 g actuator. It delivers 22 Nm peak and 9 Nm rated torque with 368 W rated power at 48 V for agile legged robots and compact arms.
Subscribe for the latest products, manufacturers and industry updates.